|
eVision C++ API 26.10.0-beta.2.dev
|
|
eVision C++ API 26.10.0-beta.2.dev
|
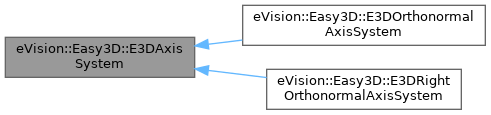
Represent a 3D base axis system. More...
#include <eVision/Easy3D/E3DAxisSystem.h>
Public Member Functions | |
| E3DAxisSystem () | |
| Constructs an E3DAxisSystem. | |
| E3DAxisSystem (const eVision::Easy3D::E3DPoint &Origin, const eVision::Easy3D::E3DPoint &axisX, const eVision::Easy3D::E3DPoint &axisY, const eVision::Easy3D::E3DPoint &axisZ) | |
| Constructs an E3DAxisSystem. | |
| E3DAxisSystem (const eVision::Easy3D::E3DAxisSystem &other) | |
| Constructs an E3DAxisSystem. | |
| virtual | ~E3DAxisSystem () throw () |
| eVision::Easy3D::E3DAxisSystem & | operator= (const eVision::Easy3D::E3DAxisSystem &other) |
| Assignment operator. | |
| bool | operator== (const eVision::Easy3D::E3DAxisSystem &other) const |
| equality operator | |
| bool | operator!= (const eVision::Easy3D::E3DAxisSystem &other) const |
| inequality operator | |
| eVision::Easy3D::E3DPoint | GetOrigin () const |
| Gets the origin. | |
| eVision::Easy3D::E3DPoint | GetAxisX () const |
| Gets the X axis. | |
| eVision::Easy3D::E3DPoint | GetAxisY () const |
| Gets the Y axis. | |
| eVision::Easy3D::E3DPoint | GetAxisZ () const |
| Gets the Z axis. | |
| float | GetNormX () const |
| Gets the norm of the X axis. | |
| float | GetNormY () const |
| Gets the norm of the Y axis. | |
| float | GetNormZ () const |
| Gets the norm of the Z axis. | |
| bool | IsRightHanded () const |
| return true if this base axis system is Right Handed | |
| bool | IsOrthogonal () const |
| return true if this base axis system is Orthogonal | |
| bool | IsNormal () const |
| return true if this base axis system is Normed | |
| void | Load (const std::string &path) |
| Load the E3DAxisSystem configuration. The given ESerializer must have been created for reading. | |
| void | Load (eVision::ESerializer *serializer) |
| Load the E3DAxisSystem configuration. The given ESerializer must have been created for reading. | |
| void | Save (const std::string &path) |
| Save the E3DAxisSystem configuration. The given ESerializer must have been created for writing. | |
| void | Save (eVision::ESerializer *serializer) |
| Save the E3DAxisSystem configuration. The given ESerializer must have been created for writing. | |
| E3DAxisSystem (CppWrapperInternal::InternalConstructor) | |
Static Public Member Functions | |
| static bool | CheckIsOrthogonal (const eVision::Easy3D::E3DPoint &axisX, const eVision::Easy3D::E3DPoint &axisY, const eVision::Easy3D::E3DPoint &axisZ) |
| check if the given axis system is Orthogonal | |
| static bool | CheckIsNormal (const eVision::Easy3D::E3DPoint &axisX, const eVision::Easy3D::E3DPoint &axisY, const eVision::Easy3D::E3DPoint &axisZ) |
| check if the given axis system is Normed | |
| static bool | CheckIsRightHanded (const eVision::Easy3D::E3DPoint &axisX, const eVision::Easy3D::E3DPoint &axisY, const eVision::Easy3D::E3DPoint &axisZ) |
| check if the given axis system is Right | |
Public Attributes | |
| CppWrapperInternal::WrappedClass | wrappedClass_ |
Represent a 3D base axis system.
License(s): Easy3D
| eVision::Easy3D::E3DAxisSystem::E3DAxisSystem | ( | ) |
Constructs an E3DAxisSystem.
| eVision::Easy3D::E3DAxisSystem::E3DAxisSystem | ( | const eVision::Easy3D::E3DPoint & | Origin, |
| const eVision::Easy3D::E3DPoint & | axisX, | ||
| const eVision::Easy3D::E3DPoint & | axisY, | ||
| const eVision::Easy3D::E3DPoint & | axisZ ) |
Constructs an E3DAxisSystem.
| Origin | The origin of the axis system |
| axisX | The X axis |
| axisY | The Y axis |
| axisZ | The Z axis |
| eVision::Easy3D::E3DAxisSystem::E3DAxisSystem | ( | const eVision::Easy3D::E3DAxisSystem & | other | ) |
Constructs an E3DAxisSystem.
| other | Reference to another E3DAxisSystem used for the initialization. |
|
virtual | ||||||||||||
| eVision::Easy3D::E3DAxisSystem::E3DAxisSystem | ( | CppWrapperInternal::InternalConstructor | ) |
|
static |
|
static |
|
static |
| eVision::Easy3D::E3DPoint eVision::Easy3D::E3DAxisSystem::GetAxisX | ( | ) | const |
Gets the X axis.
| eVision::Easy3D::E3DPoint eVision::Easy3D::E3DAxisSystem::GetAxisY | ( | ) | const |
Gets the Y axis.
| eVision::Easy3D::E3DPoint eVision::Easy3D::E3DAxisSystem::GetAxisZ | ( | ) | const |
Gets the Z axis.
| float eVision::Easy3D::E3DAxisSystem::GetNormX | ( | ) | const |
Gets the norm of the X axis.
| float eVision::Easy3D::E3DAxisSystem::GetNormY | ( | ) | const |
Gets the norm of the Y axis.
| float eVision::Easy3D::E3DAxisSystem::GetNormZ | ( | ) | const |
Gets the norm of the Z axis.
| eVision::Easy3D::E3DPoint eVision::Easy3D::E3DAxisSystem::GetOrigin | ( | ) | const |
Gets the origin.
| bool eVision::Easy3D::E3DAxisSystem::IsNormal | ( | ) | const |
return true if this base axis system is Normed
| bool eVision::Easy3D::E3DAxisSystem::IsOrthogonal | ( | ) | const |
return true if this base axis system is Orthogonal
| bool eVision::Easy3D::E3DAxisSystem::IsRightHanded | ( | ) | const |
return true if this base axis system is Right Handed
| void eVision::Easy3D::E3DAxisSystem::Load | ( | const std::string & | path | ) |
Load the E3DAxisSystem configuration. The given ESerializer must have been created for reading.
| path | The file path. |
| void eVision::Easy3D::E3DAxisSystem::Load | ( | eVision::ESerializer * | serializer | ) |
Load the E3DAxisSystem configuration. The given ESerializer must have been created for reading.
| serializer | The serializer. |
| bool eVision::Easy3D::E3DAxisSystem::operator!= | ( | const eVision::Easy3D::E3DAxisSystem & | other | ) | const |
inequality operator
| other | The other E3DAxisSystem that we will compare this one to. |
| eVision::Easy3D::E3DAxisSystem & eVision::Easy3D::E3DAxisSystem::operator= | ( | const eVision::Easy3D::E3DAxisSystem & | other | ) |
Assignment operator.
| other | The source E3DAxisSystem. |
| bool eVision::Easy3D::E3DAxisSystem::operator== | ( | const eVision::Easy3D::E3DAxisSystem & | other | ) | const |
equality operator
| other | The other E3DAxisSystem that we will compare this one to. |
| void eVision::Easy3D::E3DAxisSystem::Save | ( | const std::string & | path | ) |
Save the E3DAxisSystem configuration. The given ESerializer must have been created for writing.
| path | The file path. |
| void eVision::Easy3D::E3DAxisSystem::Save | ( | eVision::ESerializer * | serializer | ) |
Save the E3DAxisSystem configuration. The given ESerializer must have been created for writing.
| serializer | The serializer. |
| CppWrapperInternal::WrappedClass eVision::Easy3D::E3DAxisSystem::wrappedClass_ |
 1.17.0