 |
eVision .NET API
|
|
eVision .NET API
|
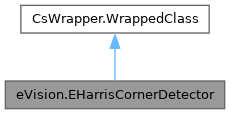
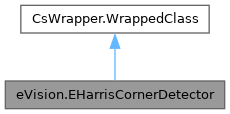
Manages a complete context for the Harris corner detector. More...
Public Member Functions | |
| EHarrisCornerDetector () | |
| Constructs a EHarrisCornerDetector object initialized to its default values. | |
| void | Apply (eVision.EROIBW8 source, eVision.EHarrisInterestPoints interestPoints) |
| Apply the Harris corner detector on an image/ROI. | |
Properties | |
| float | IntegrationScale [get, set] |
| The integration scale. | |
| float | Threshold [get, set] |
| Threshold on the cornerness measure for a pixel to be considered as a corner. | |
| bool | SubpixelPrecisionEnabled [get, set] |
| Returns whether the sub-pixel interpolation is enabled. | |
| float | DerivationScale [get, set] |
| Returns the current derivation scale. | |
| eVision.EHarrisThresholdingMode | ThresholdingMode [get, set] |
| Thresholding mode for the cornerness measure. | |
| bool | GradientNormalizationEnabled [get, set] |
| Sets whether the gradient is normalized before the computation of the cornerness measure. | |
Manages a complete context for the Harris corner detector.
This implementation of the Harris corner detector operates exclusively on a grayscale BW8 images.
License(s): EasyImage
| eVision.EHarrisCornerDetector.EHarrisCornerDetector | ( | ) |
Constructs a EHarrisCornerDetector object initialized to its default values.
| void eVision.EHarrisCornerDetector.Apply | ( | eVision.EROIBW8 | source, |
| eVision.EHarrisInterestPoints | interestPoints ) |
Apply the Harris corner detector on an image/ROI.
| source | The source image/ROI. |
| interestPoints | The container in which to store the interest points. |
|
getset |
Returns the current derivation scale.
|
getset |
Sets whether the gradient is normalized before the computation of the cornerness measure.
If this flag is enabled, the values of the X-gradient and of the Y-gradient are first divided by their maximum absolute value (in the internal computations). This results in a cornerness measure that is roughly distributed around the value 1. If this flag is disabled, the cornerness measure will be much greater.
|
getset |
The integration scale.
The integration scale is the standard deviation of the Gaussian filter that is used for scale analysis.
|
getset |
Returns whether the sub-pixel interpolation is enabled.
|
getset |
Threshold on the cornerness measure for a pixel to be considered as a corner.
If the threshold mode is set to EHarrisThresholdingMode.EHarrisThresholdingMode_Absolute, the threshold value is interpreted as an absolute threshold on the cornerness. In this case, the threshold must be a strictly positive real value.
If the threshold mode is set to EHarrisThresholdingMode.EHarrisThresholdingMode_Relative, the threshold is expressed as a fraction ranging from 0 to 1 of the maximum value of the cornerness of the source image.
|
getset |
Thresholding mode for the cornerness measure.
 1.17.0