 |
eVision .NET API
|
|
eVision .NET API
|
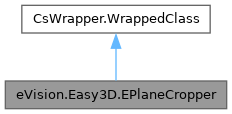
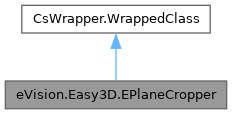
A EPlaneCropper object is used to crop some points of a EPointCloud object. More...
Public Member Functions | |
| EPlaneCropper () | |
| Creates an EPlaneCropper object using a horizontal plane as a default reference. | |
| EPlaneCropper (eVision.Easy3D.E3DPlane plane) | |
| Creates an EPlaneCropper object using a horizontal plane as a default reference. | |
| EPlaneCropper (eVision.Easy3D.EPlaneCropper other) | |
| Creates an EPlaneCropper object using a horizontal plane as a default reference. | |
| void | Load (string path) |
| Loads the EPlaneCropper configuration. The given ESerializer must have been created for reading. | |
| void | Load (eVision.ESerializer serializer) |
| Loads the EPlaneCropper configuration. The given ESerializer must have been created for reading. | |
| void | Save (string path) |
| Saves the EPlaneCropper configuration. The given ESerializer must have been created for writing. | |
| void | Save (eVision.ESerializer serializer) |
| Saves the EPlaneCropper configuration. The given ESerializer must have been created for writing. | |
| void | Crop (eVision.Easy3D.EPointCloud cloudIn, eVision.Easy3D.EPointCloud cloudOut, eVision.Easy3D.EPlaneCropperType type, float maxDistance) |
| Crops an EPointCloud. An output point cloud is produced from an input point cloud by only keeping the points that satisfy the specified condition. | |
| void | Crop (eVision.Easy3D.EPointCloud cloudIn, eVision.Easy3D.EPointCloud cloudOut, eVision.Easy3D.EPlaneCropperType type) |
| Crops an EPointCloud. An output point cloud is produced from an input point cloud by only keeping the points that satisfy the specified condition. | |
Properties | |
| eVision.Easy3D.E3DPlane | Plane [get, set] |
| Sets/gets the new reference E3DPlane of the EPlaneCropper object. | |
A EPlaneCropper object is used to crop some points of a EPointCloud object.
The points to keep are selected according to their positions with respect to a reference plane. A EPlaneCropper object is characterized by its reference plane and is used to produce an output EPointCloud object from an input EPointCloud object. The produced point cloud contains a subset of the input point cloud.
License(s): Easy3D
| eVision.Easy3D.EPlaneCropper.EPlaneCropper | ( | ) |
Creates an EPlaneCropper object using a horizontal plane as a default reference.
| eVision.Easy3D.EPlaneCropper.EPlaneCropper | ( | eVision.Easy3D.E3DPlane | plane | ) |
Creates an EPlaneCropper object using a horizontal plane as a default reference.
| plane | Reference E3DPlane used for the initialization. |
| eVision.Easy3D.EPlaneCropper.EPlaneCropper | ( | eVision.Easy3D.EPlaneCropper | other | ) |
Creates an EPlaneCropper object using a horizontal plane as a default reference.
| other | Reference EPlaneCropper used for the initialization. |
| void eVision.Easy3D.EPlaneCropper.Crop | ( | eVision.Easy3D.EPointCloud | cloudIn, |
| eVision.Easy3D.EPointCloud | cloudOut, | ||
| eVision.Easy3D.EPlaneCropperType | type ) |
Crops an EPointCloud. An output point cloud is produced from an input point cloud by only keeping the points that satisfy the specified condition.
The condition tests the (signed) distance of the points with respect to the reference plane of the cropper.
| cloudIn | The input point cloud. |
| cloudOut | The output point cloud. |
| type | An enum of type EPlaneCropperType that specifies which points of the input point cloud will be copied to the output point cloud. |
The input point cloud 'cloudIn' should be different from the output point cloud 'cloudOut'. If not a exception will be thrown.
| void eVision.Easy3D.EPlaneCropper.Crop | ( | eVision.Easy3D.EPointCloud | cloudIn, |
| eVision.Easy3D.EPointCloud | cloudOut, | ||
| eVision.Easy3D.EPlaneCropperType | type, | ||
| float | maxDistance ) |
Crops an EPointCloud. An output point cloud is produced from an input point cloud by only keeping the points that satisfy the specified condition.
The condition tests the (signed) distance of the points with respect to the reference plane of the cropper.
| cloudIn | The input point cloud. |
| cloudOut | The output point cloud. |
| type | An enum of type EPlaneCropperType that specifies which points of the input point cloud will be copied to the output point cloud. |
| maxDistance | Specifies the distance from the plane for the types "EPlaneCropperType_KeepClose" and "EPlaneCropperType_KeepFar". It should be 0 for the types "EPlaneCropperType_KeepAbove" and "EPlaneCropperType_KeepBelow. |
The input point cloud 'cloudIn' should be different from the output point cloud 'cloudOut'. If not a exception will be thrown.
| void eVision.Easy3D.EPlaneCropper.Load | ( | eVision.ESerializer | serializer | ) |
Loads the EPlaneCropper configuration. The given ESerializer must have been created for reading.
| serializer | The serializer. |
| void eVision.Easy3D.EPlaneCropper.Load | ( | string | path | ) |
Loads the EPlaneCropper configuration. The given ESerializer must have been created for reading.
| path | The file path. |
| void eVision.Easy3D.EPlaneCropper.Save | ( | eVision.ESerializer | serializer | ) |
Saves the EPlaneCropper configuration. The given ESerializer must have been created for writing.
| serializer | The ESerializer object that is written to. |
| void eVision.Easy3D.EPlaneCropper.Save | ( | string | path | ) |
Saves the EPlaneCropper configuration. The given ESerializer must have been created for writing.
| path | The file path. |
|
getset |
Sets/gets the new reference E3DPlane of the EPlaneCropper object.
 1.17.0