|
eVision C++ API 26.10.0-beta.2.dev
|
|
eVision C++ API 26.10.0-beta.2.dev
|
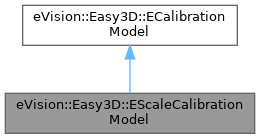
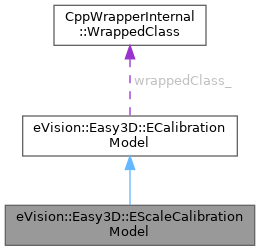
EScaleCalibrationModel is used to convert depth map 2.5D point to 3D world position, only by applying a scale factor. More...
#include <eVision/Easy3D/EScaleCalibrationModel.h>
Public Member Functions | |
| EScaleCalibrationModel () | |
| Constructs a EScaleCalibrationModel. By default parameters are initialized to default unit values. | |
| EScaleCalibrationModel (float factorX, float factorY, float factorZ) | |
| Constructs a EScaleCalibrationModel. By default parameters are initialized to default unit values. | |
| EScaleCalibrationModel (const eVision::Easy3D::EScaleCalibrationModel &other) | |
| Constructs a EScaleCalibrationModel. By default parameters are initialized to default unit values. | |
| virtual | ~EScaleCalibrationModel () throw () |
| eVision::Easy3D::EScaleCalibrationModel & | operator= (const eVision::Easy3D::EScaleCalibrationModel &other) |
| Assignment operator. | |
| bool | operator== (const eVision::Easy3D::EScaleCalibrationModel &other) const |
| Comparison operator. | |
| float | GetFactorX () const |
| Returns the width of a pixel in metric unit. | |
| float | GetFactorY () const |
| Returns the distance between 2 profiles (depth map lines) in metric unit. | |
| float | GetFactorZ () const |
| Returns the scale of the pixel value in metric unit. | |
| virtual eVision::Easy3D::ECalibrationType | GetType () const |
| Returns the type of calibration model, see ECalibrationType. | |
| void | Load (const std::string &path) |
| Loads the EScaleCalibrationModel calibration model. The given ESerializer must have been created for reading. | |
| void | Load (eVision::ESerializer *serializer) |
| Loads the EScaleCalibrationModel calibration model. The given ESerializer must have been created for reading. | |
| void | Save (const std::string &path) |
| Saves the EScaleCalibrationModel calibration model. The given ESerializer must have been created for writing. | |
| void | Save (eVision::ESerializer *serializer) |
| Saves the EScaleCalibrationModel calibration model. The given ESerializer must have been created for writing. | |
| EScaleCalibrationModel (CppWrapperInternal::InternalConstructor) | |
| Public Member Functions inherited from eVision::Easy3D::ECalibrationModel | |
| virtual | ~ECalibrationModel () throw () |
| virtual eVision::Easy3D::E3DPoint | Apply (eVision::Easy3D::E3DPoint uvwPoint) |
| Applies this model to convert an uncalibrated point to a world position. | |
| void | Load (const std::string &path) |
| Loads the calibration model. The given ESerializer must have been created for reading. | |
| void | Load (eVision::ESerializer *serializer) |
| Loads the calibration model. The given ESerializer must have been created for reading. | |
| void | Save (const std::string &path) |
| Saves the calibration model. The given ESerializer must have been created for writing. | |
| void | Save (eVision::ESerializer *serializer) |
| Saves the calibration model. The given ESerializer must have been created for writing. | |
| ECalibrationModel (CppWrapperInternal::InternalConstructor) | |
Additional Inherited Members | |
| Static Public Member Functions inherited from eVision::Easy3D::ECalibrationModel | |
| static std::unique_ptr< eVision::Easy3D::ECalibrationModel > | Create (const std::string &path) |
| Factory method from a serializer stream: allocates and reads the calibration model from the given serializer. | |
| static std::unique_ptr< eVision::Easy3D::ECalibrationModel > | Create (eVision::ESerializer *file) |
| Factory method from a serializer stream: allocates and reads the calibration model from the given serializer. | |
| Public Attributes inherited from eVision::Easy3D::ECalibrationModel | |
| CppWrapperInternal::WrappedClass | wrappedClass_ |
EScaleCalibrationModel is used to convert depth map 2.5D point to 3D world position, only by applying a scale factor.
That kind of "calibration" does not correct the perspective or distortion present in depth maps. It is a simple and fast way to get a 3D point cloud by applying a scale to each coordinate axis of the depth map pixels.
License(s): Easy3D
| eVision::Easy3D::EScaleCalibrationModel::EScaleCalibrationModel | ( | ) |
Constructs a EScaleCalibrationModel. By default parameters are initialized to default unit values.
| eVision::Easy3D::EScaleCalibrationModel::EScaleCalibrationModel | ( | float | factorX, |
| float | factorY, | ||
| float | factorZ ) |
Constructs a EScaleCalibrationModel. By default parameters are initialized to default unit values.
| factorX | Width of a pixel in metric unit (factor for X coordinate). |
| factorY | Distance between 2 profiles (depth map lines) in metric unit (factor for Y coordinate). |
| factorZ | Scale of the pixel value in metric unit (factor for Z coordinate). |
| eVision::Easy3D::EScaleCalibrationModel::EScaleCalibrationModel | ( | const eVision::Easy3D::EScaleCalibrationModel & | other | ) |
Constructs a EScaleCalibrationModel. By default parameters are initialized to default unit values.
| other | Another EScaleCalibrationModel used for the initialization. |
|
virtual | ||||||||||||
| eVision::Easy3D::EScaleCalibrationModel::EScaleCalibrationModel | ( | CppWrapperInternal::InternalConstructor | ) |
| float eVision::Easy3D::EScaleCalibrationModel::GetFactorX | ( | ) | const |
Returns the width of a pixel in metric unit.
| float eVision::Easy3D::EScaleCalibrationModel::GetFactorY | ( | ) | const |
Returns the distance between 2 profiles (depth map lines) in metric unit.
| float eVision::Easy3D::EScaleCalibrationModel::GetFactorZ | ( | ) | const |
Returns the scale of the pixel value in metric unit.
|
virtual |
Returns the type of calibration model, see ECalibrationType.
Reimplemented from eVision::Easy3D::ECalibrationModel.
| void eVision::Easy3D::EScaleCalibrationModel::Load | ( | const std::string & | path | ) |
Loads the EScaleCalibrationModel calibration model. The given ESerializer must have been created for reading.
| path | The file path. |
| void eVision::Easy3D::EScaleCalibrationModel::Load | ( | eVision::ESerializer * | serializer | ) |
Loads the EScaleCalibrationModel calibration model. The given ESerializer must have been created for reading.
| serializer | The serializer. |
| eVision::Easy3D::EScaleCalibrationModel & eVision::Easy3D::EScaleCalibrationModel::operator= | ( | const eVision::Easy3D::EScaleCalibrationModel & | other | ) |
Assignment operator.
| other | Another EScaleCalibrationModel. |
| bool eVision::Easy3D::EScaleCalibrationModel::operator== | ( | const eVision::Easy3D::EScaleCalibrationModel & | other | ) | const |
Comparison operator.
| other | Another EScaleCalibrationModel. |
| void eVision::Easy3D::EScaleCalibrationModel::Save | ( | const std::string & | path | ) |
Saves the EScaleCalibrationModel calibration model. The given ESerializer must have been created for writing.
| path | The file path. |
| void eVision::Easy3D::EScaleCalibrationModel::Save | ( | eVision::ESerializer * | serializer | ) |
Saves the EScaleCalibrationModel calibration model. The given ESerializer must have been created for writing.
| serializer | The ESerializer object that is written to. |
 1.17.0