|
eVision C++ API 26.10.0-beta.2.dev
|
|
eVision C++ API 26.10.0-beta.2.dev
|
EasyLocate tool - axis aligned bounding box version. More...
#include <eVision/EasyDeepLearning/EasyLocate/ELocator.h>
Public Member Functions | |
| ELocator () | |
| Constructs a ELocator object. | |
| ELocator (const eVision::EasyDeepLearning::ELocator &other) | |
| Copy constructor of a ELocator object. | |
| virtual | ~ELocator () throw () |
| eVision::EasyDeepLearning::ELocator & | operator= (const eVision::EasyDeepLearning::ELocator &other) |
| Assignment operator. | |
| virtual void | SerializeSettings (eVision::ESerializer *serializer) |
| Serializes the settings of the locator. | |
| virtual eVision::EasyDeepLearning::EDeepLearningToolType | GetToolType () const |
| Type of the deep learning tool. | |
| std::vector< eVision::ESize > | GenerateAnchors (const eVision::EasyDeepLearning::EDataset &dataset) const |
| Generates anchors based on the objects in the dataset or a formal specification. | |
| std::vector< eVision::ESize > | GenerateAnchors (float minDimension, float maxDimension, int numSubScales, std::vector< float > aspectRatios) const |
| Generates anchors based on the objects in the dataset or a formal specification. | |
| void | SetSameLabelMaxOverlap (float val) |
| Maximum overlap (intersection over union) between two predicted objects with the same label. | |
| float | GetSameLabelMaxOverlap () const |
| Maximum overlap (intersection over union) between two predicted objects with the same label. | |
| void | SetAbsoluteMaxOverlap (float val) |
| Maximum overlap (intersection over union) between two predicted objects regardless of their label. | |
| float | GetAbsoluteMaxOverlap () const |
| Maximum overlap (intersection over union) between two predicted objects regardless of their label. | |
| ELocator (CppWrapperInternal::InternalConstructor) | |
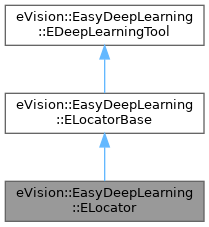
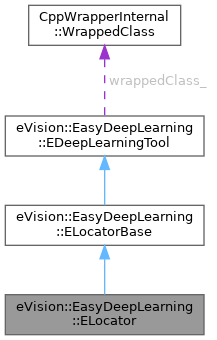
| Public Member Functions inherited from eVision::EasyDeepLearning::ELocatorBase | |
| virtual | ~ELocatorBase () throw () |
| void | SetCapacity (eVision::EasyDeepLearning::ELocatorCapacity capacity) |
| Capacity of the ELocatorBase. | |
| eVision::EasyDeepLearning::ELocatorCapacity | GetCapacity () const |
| Capacity of the ELocatorBase. | |
| void | SetWidth (uint32_t width) |
| Width of input images. | |
| uint32_t | GetWidth () const |
| Width of input images. | |
| void | SetHeight (uint32_t height) |
| Height of input images. | |
| uint32_t | GetHeight () const |
| Height of input images. | |
| void | SetChannels (uint32_t channels) |
| Number of channels of input images. It can either be 1 for grayscale images or 3 for color images. | |
| uint32_t | GetChannels () const |
| Number of channels of input images. It can either be 1 for grayscale images or 3 for color images. | |
| void | SetPredictionAnchors (const std::vector< eVision::ESize > &anchors) |
| Prediction anchors. | |
| std::vector< eVision::ESize > | GetPredictionAnchors () const |
| Prediction anchors. | |
| eVision::EasyDeepLearning::ELocatorMetrics | GetTrainingMetrics (int iteration) const |
| Training metrics at the given iteration. | |
| eVision::EasyDeepLearning::ELocatorMetrics | GetValidationMetrics (int iteration) const |
| Validation metrics at the given iteration. | |
| void | Train (eVision::EasyDeepLearning::EDataset &dataset) |
| Trains the ELocatorBase with the given dataset for the specified number of iterations. | |
| void | Train (eVision::EasyDeepLearning::EDataset &dataset, const eVision::EasyDeepLearning::EDataAugmentation &dataAugmentation) |
| Trains the ELocatorBase with the given dataset for the specified number of iterations. | |
| void | Train (eVision::EasyDeepLearning::EDataset &trainingDataset, eVision::EasyDeepLearning::EDataset &validationDataset) |
| Trains the ELocatorBase with the given dataset for the specified number of iterations. | |
| void | Train (eVision::EasyDeepLearning::EDataset &trainingDataset, eVision::EasyDeepLearning::EDataset &validationDataset, const eVision::EasyDeepLearning::EDataAugmentation &dataAugmentation) |
| Trains the ELocatorBase with the given dataset for the specified number of iterations. | |
| void | Train (eVision::EasyDeepLearning::EDataset &dataset, int iterations) |
| Trains the ELocatorBase with the given dataset for the specified number of iterations. | |
| void | Train (eVision::EasyDeepLearning::EDataset &dataset, const eVision::EasyDeepLearning::EDataAugmentation &dataAugmentation, int iterations) |
| Trains the ELocatorBase with the given dataset for the specified number of iterations. | |
| void | Train (eVision::EasyDeepLearning::EDataset &trainingDataset, eVision::EasyDeepLearning::EDataset &validationDataset, int iterations) |
| Trains the ELocatorBase with the given dataset for the specified number of iterations. | |
| void | Train (eVision::EasyDeepLearning::EDataset &trainingDataset, eVision::EasyDeepLearning::EDataset &validationDataset, const eVision::EasyDeepLearning::EDataAugmentation &dataAugmentation, int iterations) |
| Trains the ELocatorBase with the given dataset for the specified number of iterations. | |
| eVision::EasyDeepLearning::ELocatorResult | Apply (const eVision::EBaseROI &img) |
| Applies the tool on the given image and its mask region. | |
| eVision::EasyDeepLearning::ELocatorResult | Apply (const eVision::EBaseROI &img, const eVision::ERegion &mask) |
| Applies the tool on the given image and its mask region. | |
| eVision::EasyDeepLearning::ELocatorResult | Apply (const eVision::EBaseROI &img, const eVision::EFrame &frame) |
| Applies the tool on the given image and its mask region. | |
| eVision::EasyDeepLearning::ELocatorResult | Apply (const eVision::EBaseROI &img, const eVision::EFrame &frame, const eVision::ERegion &mask) |
| Applies the tool on the given image and its mask region. | |
| std::vector< eVision::EasyDeepLearning::ELocatorResult > | Apply (const std::vector< eVision::EImageBW8 > &imgs) |
| Applies the tool on the given image and its mask region. | |
| std::vector< eVision::EasyDeepLearning::ELocatorResult > | Apply (const std::vector< eVision::EImageBW8 > &imgs, const std::vector< eVision::ERegion > &masks) |
| Applies the tool on the given image and its mask region. | |
| std::vector< eVision::EasyDeepLearning::ELocatorResult > | Apply (const std::vector< eVision::EImageBW16 > &imgs) |
| Applies the tool on the given image and its mask region. | |
| std::vector< eVision::EasyDeepLearning::ELocatorResult > | Apply (const std::vector< eVision::EImageBW16 > &imgs, const std::vector< eVision::ERegion > &masks) |
| Applies the tool on the given image and its mask region. | |
| std::vector< eVision::EasyDeepLearning::ELocatorResult > | Apply (const std::vector< eVision::EImageC24 > &imgs) |
| Applies the tool on the given image and its mask region. | |
| std::vector< eVision::EasyDeepLearning::ELocatorResult > | Apply (const std::vector< eVision::EImageC24 > &imgs, const std::vector< eVision::ERegion > &masks) |
| Applies the tool on the given image and its mask region. | |
| std::vector< eVision::EasyDeepLearning::ELocatorResult > | Apply (const std::vector< const eVision::EBaseROI * > &imgs) |
| Applies the tool on the given image and its mask region. | |
| std::vector< eVision::EasyDeepLearning::ELocatorResult > | Apply (const std::vector< const eVision::EBaseROI * > &imgs, const std::vector< eVision::ERegion > &masks) |
| Applies the tool on the given image and its mask region. | |
| eVision::EasyDeepLearning::ELocatorMetrics | Evaluate (const eVision::EasyDeepLearning::EDataset &dataset) |
| Evaluates the dataset. | |
| float | GetDetectionThreshold () const |
| Detection threshold. The detection threshold is set automatically during training to maximize accuracy. It can also be changed after training to obtain a different true positive/false positive tradeoff. | |
| void | SetDetectionThreshold (float threshold) |
| Detection threshold. The detection threshold is set automatically during training to maximize accuracy. It can also be changed after training to obtain a different true positive/false positive tradeoff. | |
| void | SetMaxNumberOfObjects (int val) |
| Maximum number of objects in an image (default value: 100). | |
| int | GetMaxNumberOfObjects () const |
| Maximum number of objects in an image (default value: 100). | |
| void | SetSameLabelMaxObjectProximity (float val) |
| Maximum proximity between two predicted objects with the same label. | |
| float | GetSameLabelMaxObjectProximity () const |
| Maximum proximity between two predicted objects with the same label. | |
| void | SetAbsoluteMaxObjectProximity (float val) |
| Maximum proximity between two predicted objects regardless of their label. | |
| float | GetAbsoluteMaxObjectProximity () const |
| Maximum proximity between two predicted objects regardless of their label. | |
| int | GetLocatorFeatures () const |
| The features supported by the locator. | |
| bool | HasFeature (eVision::EasyDeepLearning::ELocatorFeature feature) |
| Whether the given feature is enabled. | |
| ELocatorBase (CppWrapperInternal::InternalConstructor) | |
| Public Member Functions inherited from eVision::EasyDeepLearning::EDeepLearningTool | |
| virtual | ~EDeepLearningTool () throw () |
| virtual void | Load (const std::string &filePath) |
| Loads a deep learning tool. The given ESerializer must have been created for reading. | |
| virtual void | Load (eVision::ESerializer *serializer) |
| Loads a deep learning tool. The given ESerializer must have been created for reading. | |
| std::unique_ptr< eVision::EasyDeepLearning::EDeepLearningTool > | Clone () const |
| Clones this tool. | |
| virtual void | Save (const std::string &filePath, bool includeTrainingModel) |
| Saves the settings, inference and training model of the deep learning tool. | |
| virtual void | Save (const std::string &filePath) |
| Saves the settings, inference and training model of the deep learning tool. | |
| virtual void | Save (eVision::ESerializer *serializer, bool includeTrainingModel) |
| Saves the settings, inference and training model of the deep learning tool. | |
| virtual void | Save (eVision::ESerializer *serializer) |
| Saves the settings, inference and training model of the deep learning tool. | |
| void | SerializeInferenceModel (eVision::ESerializer *serializer) |
| Serializes the inference model of the tool. | |
| void | SerializeTrainingModel (eVision::ESerializer *serializer) |
| Serializes the training model of the tool. | |
| void | SaveSettings (const std::string &filePath) |
| Saves the settings of the tool to a file. | |
| void | SaveInferenceModel (const std::string &filePath) |
| Saves the tool's inference model to a file. | |
| void | SaveTrainingModel (const std::string &filePath) |
| Saves the tool's training model to a file. | |
| void | LoadSettings (const std::string &filePath) |
| Loads the settings of a tool. | |
| void | LoadInferenceModel (const std::string &filePath) |
| Loads the tool's inference model. The inference model is required to apply the tool on new images. | |
| void | LoadTrainingModel (const std::string &filePath) |
| Loads the tool's training model. The training model is required to continue a training. | |
| void | UnloadInferenceModel () |
| Unloads the inference model. | |
| void | UnloadTrainingModel () |
| Unloads the training model. | |
| void | UnloadModels () |
| Unloads the inference and training model. | |
| bool | HasInferenceModel () const |
| Whether the inference model is loaded or created when the tool is not yet trained. | |
| bool | HasTrainingModel () const |
| Whether the training model is loaded or created when the tool is not yet trained. | |
| bool | IsTrained () const |
| Tells whether the deep learning tool has been trained. | |
| void | SetEnableGPU (bool enable) |
| Enable the use of a GPU for training and inference of the deep learning tool. If the active engine is not the default engine, EDeepLearningTool::SetEnableGPU will be false even if the active device has a GPU device type. Setting EDeepLearningTool::SetEnableGPU to any value when the active engine is not the default one will throw an exception. | |
| bool | GetEnableGPU () const |
| Enable the use of a GPU for training and inference of the deep learning tool. If the active engine is not the default engine, EDeepLearningTool::SetEnableGPU will be false even if the active device has a GPU device type. Setting EDeepLearningTool::SetEnableGPU to any value when the active engine is not the default one will throw an exception. | |
| void | SetGPUIndexes (const std::vector< uint32_t > &indexes) |
| Indexes of the GPUs to use for computations. | |
| std::vector< uint32_t > | GetGPUIndexes () const |
| Indexes of the GPUs to use for computations. | |
| uint32_t | GetNumGPUs () const |
| Number of detected NVIDIA GPU. | |
| void | SetEngine (const std::string &engineName) |
| Sets the engine with which to execute or train the neural network. | |
| std::string | GetEngine () const |
| Sets the engine with which to execute or train the neural network. | |
| eVision::EasyDeepLearning::EDeepLearningInferencePrecision | GetInferencePrecision () const |
| Inference precision. | |
| void | SetInferencePrecision (eVision::EasyDeepLearning::EDeepLearningInferencePrecision prec) |
| Inference precision. | |
| int | GetNumAvailableDevices () const |
| Available devices for the current EDeepLearningTool::SetEngine. | |
| std::string | GetAvailableDeviceName (int i) const |
| Name of the i-th device of the current engine. | |
| eVision::EasyDeepLearning::EDeepLearningDevice | GetAvailableDevice (int i) const |
| i-th EDeepLearningDevice of the current engine. | |
| std::vector< eVision::EasyDeepLearning::EDeepLearningDevice > | GetAvailableDevices () const |
| Get all available device for the current engine. | |
| int | GetNumActiveDevices () const |
| Gets the number of devices with which to run or train the model. | |
| void | SetActiveDevice (const eVision::EasyDeepLearning::EDeepLearningDevice &device) |
| Sets the device with which to run or train the model. | |
| eVision::EasyDeepLearning::EDeepLearningDevice | GetActiveDevice (int i) const |
| Gets the active device. By default, it returns the first active device. | |
| eVision::EasyDeepLearning::EDeepLearningDevice | GetActiveDevice () const |
| Gets the active device. By default, it returns the first active device. | |
| void | SetActiveDeviceByName (const std::string &name) |
| Sets the device with which to run the model using its name. | |
| void | SetActiveDeviceById (int id) |
| Sets the device with which to run the model using its index in the list returned by EDeepLearningTool::GetAvailableDevices. | |
| std::vector< eVision::EasyDeepLearning::EDeepLearningDevice > | GetActiveDevices () const |
| Devices with which to run or train the model. | |
| void | SetActiveDevices (const std::vector< eVision::EasyDeepLearning::EDeepLearningDevice > &devices) |
| Devices with which to run or train the model. | |
| void | SetActiveDevicesById (const std::vector< int > &ids) |
| Sets the devices with which to run the model using their index in the list returned by EDeepLearningTool::GetAvailableDevices. | |
| eVision::EasyDeepLearning::EDeepLearningExecutionSettings | GetExecutionSettings () const |
| Execution settings of the tool (engine, device(s), inference precision, batch size settings). | |
| void | SetExecutionSettings (const eVision::EasyDeepLearning::EDeepLearningExecutionSettings &settings) |
| Execution settings of the tool (engine, device(s), inference precision, batch size settings). | |
| bool | HasEngineSetupData () const |
| Whether the inference model has engine setup data. | |
| void | ClearEngineSetupData () |
| Clears the engine data saved in the inference model. Use this method when your engine fails. | |
| eVision::EasyDeepLearning::EDeepLearningDevice | GetEngineSetupDataDevice () const |
| Device corresponding to the engine data contained in the tool. | |
| eVision::EasyDeepLearning::EDeepLearningInferencePrecision | GetEngineSetupDataInferencePrecision () const |
| Inference precision corresponding to the engine data contained in the tool. | |
| int32_t | GetEngineSetupDataBatchSize () const |
| Batch size corresponding to the engine data contained in the tool. | |
| bool | GetOptimizeBatchSize () const |
| Indicates whether to optimize the batch size (see EDeepLearningTool::SetBatchSize) to maximize the training and inference speed according to the engine, the device and the available memory. | |
| void | SetOptimizeBatchSize (bool optimize) |
| Indicates whether to optimize the batch size (see EDeepLearningTool::SetBatchSize) to maximize the training and inference speed according to the engine, the device and the available memory. | |
| int32_t | GetBatchSizeForMaximumInferenceSpeed () const |
| Computes the batch size that will maximize the inference speed on NVIDIA GPU. For all other devices, it will return 1. | |
| void | SetBatchSize (int32_t size) |
| Batch size. The batch size is the number of images that are processed together during training and batch inference. | |
| int32_t | GetBatchSize () const |
| Batch size. The batch size is the number of images that are processed together during training and batch inference. | |
| bool | IsTraining () const |
| Indicates whether the object is currently training. | |
| int | WaitForTrainingCompletion (int timeout) |
| Waits until the training is complete or the timeout is expired. A call to this method will block the calling thread for the shortest time between the timeout and the time it takes for the training to complete. | |
| int | WaitForTrainingCompletion () |
| Waits until the training is complete or the timeout is expired. A call to this method will block the calling thread for the shortest time between the timeout and the time it takes for the training to complete. | |
| int | WaitForIterationCompletion () |
| Waits until an iteration is complete. A call to this method will block the calling thread until a training iteration in the training thread is finished. This method returns the number of trained iterations. | |
| int | StopTraining (bool wait) |
| Stops training and returns the last completed iteration. If the parameter 'wait' is set to true, the method will wait for the training thread to completely stop. Otherwise, the method will return immediately. | |
| float | GetCurrentTrainingProgression () const |
| Current training progression as a percentage (between 0 and 1). | |
| uint32_t | GetCurrentTrainingFinishedIterations () const |
| Number of iterations that are already finished in the current training. | |
| uint32_t | GetCurrentTrainingNumIterations () const |
| Total number of training iterations that will be performed during the current training of the deep learning tool. | |
| uint32_t | GetNumTrainedIterations () const |
| Number of iterations that were performed to train this deep learning tool. | |
| int | GetBestIteration () const |
| Iteration at which the minimum validation error was reached. After training, the tool is in the state it was at this best iteration. | |
| void | SetImageCacheSize (uint64_t size) |
| Size in byte of the image cache. The cache is used during training to store reformatted and normalized images. A correctly sized cache can reduce the hard drive accesses and the preprocessing time for each image. | |
| uint64_t | GetImageCacheSize () const |
| Size in byte of the image cache. The cache is used during training to store reformatted and normalized images. A correctly sized cache can reduce the hard drive accesses and the preprocessing time for each image. | |
| std::string | GetPath () const |
| Path of the tool when loaded or saved using EDeepLearningTool::Save or EDeepLearningTool::Load. | |
| std::string | GetInferenceModelPath () const |
| Path of the inference model when loaded or saved using EDeepLearningTool::SaveInferenceModel, EDeepLearningTool::LoadInferenceModel or EDeepLearningTool::SerializeInferenceModel. | |
| std::string | GetTrainingModelPath () const |
| Path of the training model when loaded or saved using EDeepLearningTool::SaveTrainingModel, EDeepLearningTool::LoadTrainingModel or EDeepLearningTool::SerializeTrainingModel. | |
| std::string | GetSettingsPath () const |
| Path of the settings when loaded or saved using EDeepLearningTool::SaveSettings, EDeepLearningTool::LoadSettings or EDeepLearningTool::SerializeSettings. | |
| void | SetAutoSavePeriod (int period) |
| Auto-save period. The auto-save period is the number of training iterations between each automatic save of the model. | |
| int | GetAutoSavePeriod () const |
| Auto-save period. The auto-save period is the number of training iterations between each automatic save of the model. | |
| void | SetLearningRate (eVision::EasyDeepLearning::EDeepLearningLearningRateType type, const std::vector< float > ¶meters) |
| Specifies how the value of the learning rate and how it evolves during training. | |
| eVision::EasyDeepLearning::EDeepLearningLearningRateType | GetLearningRateType () const |
| Learning rate type. | |
| std::vector< float > | GetLearningRateParameters () const |
| Parameters of the learning rate. | |
| void | SetEnableDeterministicTraining (bool enable) |
| Whether to use deterministic training algorithm that allows to repeatable training results. Default value: false. | |
| bool | GetEnableDeterministicTraining () const |
| Whether to use deterministic training algorithm that allows to repeatable training results. Default value: false. | |
| void | SetDeterministicTrainingRandomSeed (int32_t seed) |
| Random seed to use when EDeepLearningTool::SetEnableDeterministicTraining is set to true. The default value is 42. | |
| int32_t | GetDeterministicTrainingRandomSeed () const |
| Random seed to use when EDeepLearningTool::SetEnableDeterministicTraining is set to true. The default value is 42. | |
| void | InitializeInference (int width, int height, eVision::EImageType imageType, int numImages) |
| Initializes the neural network for inference (i.e. making predictions with the neural network). | |
| void | InitializeInference (const eVision::EBaseROI &img) |
| Initializes the neural network for inference (i.e. making predictions with the neural network). | |
| void | InitializeInference (std::vector< const eVision::EBaseROI * > &imgList) |
| Initializes the neural network for inference (i.e. making predictions with the neural network). | |
| void | InitializeInference (std::vector< eVision::EImageBW8 > &imgList) |
| Initializes the neural network for inference (i.e. making predictions with the neural network). | |
| void | InitializeInference (std::vector< eVision::EImageBW16 > &imgList) |
| Initializes the neural network for inference (i.e. making predictions with the neural network). | |
| void | InitializeInference (std::vector< eVision::EImageC24 > &imgList) |
| Initializes the neural network for inference (i.e. making predictions with the neural network). | |
| uint32_t | GetNumLabels () const |
| Number of labels of this tool. If the tool is not trained, the method will throw an exception. | |
| std::string | GetLabel (uint32_t index) const |
| Gets the label from its index. If the tool is not trained, the method may throw an exception. | |
| virtual void | SetLabel (uint32_t index, const std::string &label) |
| Changes a label predicted by the tool. | |
| void | SetLabelWeight (uint32_t index, float weight) |
| Sets the label weight. If the tool is not trained, the label weights are not defined. After training, they are set to the value of the training dataset label weights. | |
| float | GetLabelWeight (uint32_t index) const |
| Gets the label weight. If the tool is not trained, the label weights are not defined. After training, they are set to the value of the training dataset label weights. | |
| void | SetLabelColor (uint32_t index, const eVision::ERGBColor &c) |
| Changes a label color. | |
| eVision::ERGBColor | GetLabelColor (uint32_t index) const |
| Label color. The label colors affect how the results will be displayed. | |
| void | SetLabelOpacity (uint32_t index, uint8_t opacity) |
| Changes a label opacity (between 0 for fully transparent and 255 for opaque color). | |
| uint8_t | GetLabelOpacity (uint32_t index) const |
| Gets the label opacity (between 0 for fully transparent and 255 for opaque color). The label opacities affect with the label colors how the results will be displayed. | |
| int | GetOptimalNumImagesForBatchSize (const eVision::EBaseROI &sampleImage) const |
| Optimal number of images to process together for inference given the batch size and EDeepLearningTool::GetNumPatchesForImage. | |
| int | GetOptimalNumImagesForBatchSize (int imageWidth, int imageHeight) const |
| Optimal number of images to process together for inference given the batch size and EDeepLearningTool::GetNumPatchesForImage. | |
| int | GetNumPatchesForImage (const eVision::EBaseROI &sampleImage) const |
| Number of patches that will be extracted from an input image to perform inference. | |
| virtual int | GetNumPatchesForImage (int imageWidth, int imageHeight) const |
| Number of patches that will be extracted from an input image to perform inference. | |
| virtual void | Clean () |
| Reset the engine and clean CPU and GPU memory allocated for running the model. | |
| EDeepLearningTool (CppWrapperInternal::InternalConstructor) | |
Additional Inherited Members | |
| Static Public Member Functions inherited from eVision::EasyDeepLearning::EDeepLearningTool | |
| static std::unique_ptr< eVision::EasyDeepLearning::EDeepLearningTool > | Create (const std::string &path) |
| Factory method to open a deep learning tool. | |
| static std::unique_ptr< eVision::EasyDeepLearning::EDeepLearningTool > | Create (eVision::ESerializer *serializer) |
| Factory method to open a deep learning tool. | |
| static std::unique_ptr< eVision::EasyDeepLearning::EDeepLearningTool > | Create (eVision::EasyDeepLearning::EDeepLearningToolType type) |
| Factory method to open a deep learning tool. | |
| static int | GetNumAvailableEngines () |
| Number of available engines. | |
| static std::string | GetAvailableEngineName (int id) |
| Gets the name of the engine given its id. | |
| static std::vector< std::string > | GetAvailableEngines () |
| Available engines. | |
| static std::vector< eVision::EasyDeepLearning::EDeepLearningDevice > | GetAvailableDevicesForEngine (const std::string &engine) |
| Available devices for the specified engine. | |
| Public Attributes inherited from eVision::EasyDeepLearning::EDeepLearningTool | |
| CppWrapperInternal::WrappedClass | wrappedClass_ |
EasyLocate tool - axis aligned bounding box version.
The ELocator locates and classifies objects (or defects). With this class, an object is defined by the axis-aligned bounding box that surrounds it and a label (see ELocatorObject class). The tool must be trained using a dataset with annotated objects. The minimum size resolution supported by the tool is 128. The maximum size of the image supported is 500 000 pixels.
The tool has 5 main parameters:
License(s): EasyLocate or EasyLocateInference
| eVision::EasyDeepLearning::ELocator::ELocator | ( | ) |
Constructs a ELocator object.
| eVision::EasyDeepLearning::ELocator::ELocator | ( | const eVision::EasyDeepLearning::ELocator & | other | ) |
|
virtual | ||||||||||||
| eVision::EasyDeepLearning::ELocator::ELocator | ( | CppWrapperInternal::InternalConstructor | ) |
| std::vector< eVision::ESize > eVision::EasyDeepLearning::ELocator::GenerateAnchors | ( | const eVision::EasyDeepLearning::EDataset & | dataset | ) | const |
Generates anchors based on the objects in the dataset or a formal specification.
For the version that takes a dataset, the properties ELocatorBase::SetWidth and ELocatorBase::SetHeight must be set.
| dataset | Dataset |
The dimension of an object corresponds to the square root of its area.
| std::vector< eVision::ESize > eVision::EasyDeepLearning::ELocator::GenerateAnchors | ( | float | minDimension, |
| float | maxDimension, | ||
| int | numSubScales, | ||
| std::vector< float > | aspectRatios ) const |
Generates anchors based on the objects in the dataset or a formal specification.
For the version that takes a dataset, the properties ELocatorBase::SetWidth and ELocatorBase::SetHeight must be set.
| minDimension | Minimum dimension of objects (minimum value: 16) |
| maxDimension | Maximum dimension of objects. |
| numSubScales | Number of sub-scales to produce for each scale covered by the given dimensions. |
| aspectRatios | Aspect ratios to generate at each scale. The aspect ratios are the ratios between the width and height of the anchor. Recommended value: {1.0f, 0.5f, 2.0f}. |
The dimension of an object corresponds to the square root of its area.
| float eVision::EasyDeepLearning::ELocator::GetAbsoluteMaxOverlap | ( | ) | const |
Maximum overlap (intersection over union) between two predicted objects regardless of their label.
The value of the parameter must be between 0 (no overlap allowed between two predicted objects with different labels) and 1 (full overlap allowed between two predicted objects with different labels).
Default value: 1.
This parameter can be changed before and after training.
| float eVision::EasyDeepLearning::ELocator::GetSameLabelMaxOverlap | ( | ) | const |
Maximum overlap (intersection over union) between two predicted objects with the same label.
The value of the parameter must be between 0 (no overlap allowed between two predicted objects with the same label) and 1 (full overlap allowed between two predicted objects with the same label). A low value will reduce the amount of falsely detected objects but may increase the number of missed objects. A high value will increase the number of falsely detected objects and reduce the number of missed objects.
Default value: 0.5
This parameter is also used to compute the matching between ground truth and predicted objects during evaluation.
This parameter can be changed before and after training.
|
virtual |
Type of the deep learning tool.
Implements eVision::EasyDeepLearning::EDeepLearningTool.
| eVision::EasyDeepLearning::ELocator & eVision::EasyDeepLearning::ELocator::operator= | ( | const eVision::EasyDeepLearning::ELocator & | other | ) |
Assignment operator.
| other | Reference to the ELocator object that should be copied |
|
virtual |
Serializes the settings of the locator.
| serializer | Pointer to ESerializer |
Reimplemented from eVision::EasyDeepLearning::ELocatorBase.
| void eVision::EasyDeepLearning::ELocator::SetAbsoluteMaxOverlap | ( | float | val | ) |
Maximum overlap (intersection over union) between two predicted objects regardless of their label.
The value of the parameter must be between 0 (no overlap allowed between two predicted objects with different labels) and 1 (full overlap allowed between two predicted objects with different labels).
Default value: 1.
| val | Maximum overlap |
This parameter can be changed before and after training.
| void eVision::EasyDeepLearning::ELocator::SetSameLabelMaxOverlap | ( | float | val | ) |
Maximum overlap (intersection over union) between two predicted objects with the same label.
The value of the parameter must be between 0 (no overlap allowed between two predicted objects with the same label) and 1 (full overlap allowed between two predicted objects with the same label). A low value will reduce the amount of falsely detected objects but may increase the number of missed objects. A high value will increase the number of falsely detected objects and reduce the number of missed objects.
Default value: 0.5
| val | Maximum overlap |
This parameter is also used to compute the matching between ground truth and predicted objects during evaluation.
This parameter can be changed before and after training.
 1.17.0