 |
eVision .NET API
|
|
eVision .NET API
|
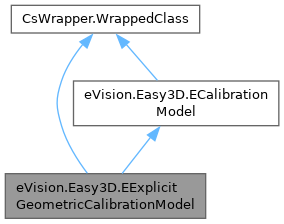
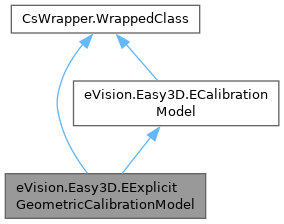
EExplicitGeometricCalibrationModel is used to calibrate a depth map from a minimal set of explicit geometric values. More...
Public Member Functions | |
| EExplicitGeometricCalibrationModel () | |
| Constructs a EExplicitGeometricCalibrationModel. EExplicitGeometricCalibrationModel is used to calibrate a depth map from a minimal set of explicit geometric values. | |
| EExplicitGeometricCalibrationModel (float sensorWidth, float sensorHeight, int sensorXResolution, int sensorYResolution, int roiLeftColumn, int roiBottomLine, float focalLength, float cameraAngle, float cameraHeight, float laserPlaneAngle, float motionIncrement) | |
| Constructs a EExplicitGeometricCalibrationModel. EExplicitGeometricCalibrationModel is used to calibrate a depth map from a minimal set of explicit geometric values. | |
| EExplicitGeometricCalibrationModel (eVision.Easy3D.EExplicitGeometricCalibrationModel other) | |
| Constructs a EExplicitGeometricCalibrationModel. EExplicitGeometricCalibrationModel is used to calibrate a depth map from a minimal set of explicit geometric values. | |
| bool | IsInitialized () |
| Returns true if the model has been correctly initialized. | |
| new void | Load (string path) |
| Loads the EExplicitGeometricCalibrationModel. The given ESerializer must have been created for reading. | |
| new void | Load (eVision.ESerializer serializer) |
| Loads the EExplicitGeometricCalibrationModel. The given ESerializer must have been created for reading. | |
| new void | Save (string path) |
| Saves the EExplicitGeometricCalibrationModel. The given ESerializer must have been created for writing. | |
| new void | Save (eVision.ESerializer serializer) |
| Saves the EExplicitGeometricCalibrationModel. The given ESerializer must have been created for writing. | |
| Public Member Functions inherited from eVision.Easy3D.ECalibrationModel | |
| virtual eVision.Easy3D.E3DPoint | Apply (eVision.Easy3D.E3DPoint uvwPoint) |
| Applies this model to convert an uncalibrated point to a world position. | |
| void | Load (string path) |
| Loads the calibration model. The given ESerializer must have been created for reading. | |
| void | Load (eVision.ESerializer serializer) |
| Loads the calibration model. The given ESerializer must have been created for reading. | |
| void | Save (string path) |
| Saves the calibration model. The given ESerializer must have been created for writing. | |
| void | Save (eVision.ESerializer serializer) |
| Saves the calibration model. The given ESerializer must have been created for writing. | |
Properties | |
| float | SensorWidth [get] |
| Camera sensor width. | |
| float | SensorHeight [get] |
| Camera sensor height. | |
| int | SensorXResolution [get] |
| Camera X resolution. | |
| int | SensorYResolution [get] |
| Camera Y resolution. | |
| int | RoiLeftColumn [get] |
| The ROI left column used in laser line extraction. | |
| int | RoiBottomLine [get] |
| The ROI bottom line used in laser line extraction. | |
| float | FocalLength [get] |
| Camera focal length. | |
| float | CameraAngle [get] |
| Camera view angle. | |
| float | LaserPlaneAngle [get] |
| Laser plane angle. | |
| float | CameraHeight [get] |
| The height from the camera optical center to the object reference plane (assuming the reference plane is projected in the center line of the image), in mm. | |
| float | MotionIncrement [get] |
| Motion increment (Distance between each line of the depth map). | |
| override eVision.Easy3D.ECalibrationType | Type [get] |
| Returns the type of calibration model, see ECalibrationType. | |
| Properties inherited from eVision.Easy3D.ECalibrationModel | |
| virtual eVision.Easy3D.ECalibrationType | Type [get] |
| Returns the type of calibration model, see ECalibrationType. | |
Additional Inherited Members | |
| Static Public Member Functions inherited from eVision.Easy3D.ECalibrationModel | |
| static eVision.Easy3D.ECalibrationModel | Create (string path) |
| Factory method from a serializer stream: allocates and reads the calibration model from the given serializer. | |
| static eVision.Easy3D.ECalibrationModel | Create (eVision.ESerializer file) |
| Factory method from a serializer stream: allocates and reads the calibration model from the given serializer. | |
EExplicitGeometricCalibrationModel is used to calibrate a depth map from a minimal set of explicit geometric values.
All model parameters are given to the EExplicitGeometricCalibrationModel constructor.
License(s): Easy3DLaserLine
| eVision.Easy3D.EExplicitGeometricCalibrationModel.EExplicitGeometricCalibrationModel | ( | ) |
Constructs a EExplicitGeometricCalibrationModel. EExplicitGeometricCalibrationModel is used to calibrate a depth map from a minimal set of explicit geometric values.
| eVision.Easy3D.EExplicitGeometricCalibrationModel.EExplicitGeometricCalibrationModel | ( | float | sensorWidth, |
| float | sensorHeight, | ||
| int | sensorXResolution, | ||
| int | sensorYResolution, | ||
| int | roiLeftColumn, | ||
| int | roiBottomLine, | ||
| float | focalLength, | ||
| float | cameraAngle, | ||
| float | cameraHeight, | ||
| float | laserPlaneAngle, | ||
| float | motionIncrement ) |
Constructs a EExplicitGeometricCalibrationModel. EExplicitGeometricCalibrationModel is used to calibrate a depth map from a minimal set of explicit geometric values.
| sensorWidth | The camera sensor width, in mm. |
| sensorHeight | The camera sensor height, in mm. |
| sensorXResolution | The camera X resolution (pixel count in width). |
| sensorYResolution | The camera Y resolution (pixel count in height). |
| roiLeftColumn | The ROI left column used in laser line extraction. Between the left (0) and the right (width) of the image. |
| roiBottomLine | The ROI bottom line used in laser line extraction. Between the top (0) and the bottom (height) of the image. That's the depth map values origin. |
| focalLength | The camera optics focal length, in mm. |
| cameraAngle | The camera angle from the vertical axis. Looking down camera is angle 0 and positive in counter clockwise direction. Valid values are between 0 (vertical orientation) and lower that 90 degrees (horizontal orientation). |
| cameraHeight | The height from the camera optical center to the object reference plane (assuming the reference plane is projected in the center line of the image), in mm. |
| laserPlaneAngle | The laser plane angle from the vertical axis. A perfect vertical laser orientation is angle 0 and negative in clockwise direction. Valid values for laser angle are between -90 degrees (excluded) and +90 degrees (excluded). |
| motionIncrement | The distance in mm between each line of the depth map. That's the relative motion of the camera/laser setup to the object position. |
| eVision.Easy3D.EExplicitGeometricCalibrationModel.EExplicitGeometricCalibrationModel | ( | eVision.Easy3D.EExplicitGeometricCalibrationModel | other | ) |
Constructs a EExplicitGeometricCalibrationModel. EExplicitGeometricCalibrationModel is used to calibrate a depth map from a minimal set of explicit geometric values.
| other | Another EExplicitGeometricCalibrationModel. |
| bool eVision.Easy3D.EExplicitGeometricCalibrationModel.IsInitialized | ( | ) |
Returns true if the model has been correctly initialized.
| new void eVision.Easy3D.EExplicitGeometricCalibrationModel.Load | ( | eVision.ESerializer | serializer | ) |
Loads the EExplicitGeometricCalibrationModel. The given ESerializer must have been created for reading.
| serializer | The serializer. |
| new void eVision.Easy3D.EExplicitGeometricCalibrationModel.Load | ( | string | path | ) |
Loads the EExplicitGeometricCalibrationModel. The given ESerializer must have been created for reading.
| path | The file path. |
| new void eVision.Easy3D.EExplicitGeometricCalibrationModel.Save | ( | eVision.ESerializer | serializer | ) |
Saves the EExplicitGeometricCalibrationModel. The given ESerializer must have been created for writing.
| serializer | The serializer. |
| new void eVision.Easy3D.EExplicitGeometricCalibrationModel.Save | ( | string | path | ) |
Saves the EExplicitGeometricCalibrationModel. The given ESerializer must have been created for writing.
| path | The file path. |
|
get |
Camera view angle.
|
get |
The height from the camera optical center to the object reference plane (assuming the reference plane is projected in the center line of the image), in mm.
|
get |
Camera focal length.
|
get |
Laser plane angle.
|
get |
Motion increment (Distance between each line of the depth map).
|
get |
The ROI bottom line used in laser line extraction.
|
get |
The ROI left column used in laser line extraction.
|
get |
Camera sensor height.
|
get |
Camera sensor width.
|
get |
Camera X resolution.
|
get |
Camera Y resolution.
|
get |
Returns the type of calibration model, see ECalibrationType.
 1.17.0