 |
eVision .NET API
|
|
eVision .NET API
|
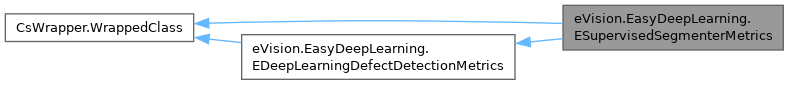
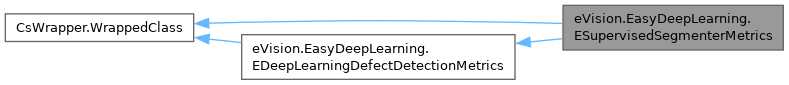
Collection of metrics used to evaluate the state of a ESupervisedSegmenter tool. More...
Public Member Functions | |
| ESupervisedSegmenterMetrics () | |
| Constructs an ESupervisedSegmenterMetrics object. | |
| ESupervisedSegmenterMetrics (eVision.EasyDeepLearning.ESupervisedSegmenterMetrics other) | |
| Copy constructor of an ESupervisedSegmenterMetrics object. | |
| override void | Load (string path) |
| Loads an supervised segmentation metric. The given ESerializer must have been created for reading. | |
| override void | Load (eVision.ESerializer serializer) |
| Loads an supervised segmentation metric. The given ESerializer must have been created for reading. | |
| override void | Save (string path) |
| Saves an supervised segmentation metric. The given ESerializer must have been created for writing. | |
| override void | Save (eVision.ESerializer serializer) |
| Saves an supervised segmentation metric. The given ESerializer must have been created for writing. | |
| bool | IsValid () |
| Indicates whether the object contains at least one result. | |
| float | GetPixelLabelAccuracy (string label) |
| Pixel label accuracy. | |
| float | GetLabelError (string label) |
| Label error. | |
| ulong | GetPixelConfusion (string trueLabel, string predictedLabel) |
| Pixel-wise confusion between the given true and predicted labels. | |
| float | GetNormalizedPixelConfusion (string trueLabel, string predictedLabel) |
| Pixel-wise normalized confusion between the given true and predicted labels. | |
| float | GetIntersectionOverUnion (string label) |
| Intersection over union. | |
| ulong | GetGroundtruthBlobConfusion (string groundtruthLabel, string predictedLabel) |
| Number of ground truth blobs of the given ground truth label that best match with blobs of the given predicted label. | |
| ulong | GetGroundtruthBlobConfusion (int groundtruthLabelIndex, int predictedLabelIndex) |
| Number of ground truth blobs of the given ground truth label that best match with blobs of the given predicted label. | |
| ulong | GetPredictedBlobConfusion (string groundtruthLabel, string predictedLabel) |
| Number of predicted blobs of the given predicted label that match to blobs of the given ground truth label. | |
| ulong | GetPredictedBlobConfusion (int groundtruthLabelIndex, int predictedLabelIndex) |
| Number of predicted blobs of the given predicted label that match to blobs of the given ground truth label. | |
| string | GetLabel (int labelIdx) |
| Label recognized by the segmenter that produced the results aggregated in the metrics. | |
| Public Member Functions inherited from eVision.EasyDeepLearning.EDeepLearningDefectDetectionMetrics | |
| EDeepLearningDefectDetectionMetrics () | |
| Constructs an empty EDeepLearningDefectDetectionMetrics object. | |
| EDeepLearningDefectDetectionMetrics (eVision.EasyDeepLearning.EDeepLearningDefectDetectionMetrics other) | |
| Copy constructor. | |
| bool | IsDefectDetectionMetricsValid () |
| Whether the defect detection metrics are valid or not. Defect detection metrics are completely valid when the metrics has results for at least one good and one defective images. Some metrics might be valid with only defective or good results. | |
| float | GetAccuracy (int index) |
| The accuracy of the segmenter. | |
| float | GetAccuracy () |
| The accuracy of the segmenter. | |
| float | GetBestWeightedAccuracy (float goodWeight, float badWeight) |
| Best achievable weighted accuracy. | |
| float | GetBestWeightedAccuracyClassificationThreshold (float goodWeight, float badWeight) |
| Classification threshold giving the best achievable weighted accuracy (see EDeepLearningDefectDetectionMetrics.GetBestWeightedAccuracy). | |
| uint | GetConfusion (eVision.EasyDeepLearning.EConfusionMatrixElement element, int index) |
| Confusion value of one label with another. | |
| uint | GetConfusion (eVision.EasyDeepLearning.EConfusionMatrixElement element) |
| Confusion value of one label with another. | |
| float | GetRecall (int index) |
| Recall for the current threshold. | |
| float | GetRecall () |
| Recall for the current threshold. | |
| float | GetPrecision (int index) |
| Precision for the current threshold. | |
| float | GetPrecision () |
| Precision for the current threshold. | |
| float | GetFScore (int index) |
| The F1-Score for the current threshold. | |
| float | GetFScore () |
| The F1-Score for the current threshold. | |
| eVision.EasyDeepLearning.EROCPoint | GetPrecisionRecallCurvePoint (int index) |
| Get a point on the precision/recall curve. | |
| eVision.EasyDeepLearning.EROCPoint | GetPrecisionRecallCurvePoint () |
| Get a point on the precision/recall curve. | |
| eVision.EasyDeepLearning.EROCPoint | GetROCPoint (int index) |
| ROC (Receiver Operating Characteristic) point. | |
| eVision.EasyDeepLearning.EROCPoint | GetROCPoint () |
| ROC (Receiver Operating Characteristic) point. | |
Properties | |
| float | WeightedPixelAccuracy [get] |
| Weighted accuracy. | |
| float | BalancedPixelAccuracy [get] |
| Balanced accuracy. | |
| float | PixelAccuracy [get] |
| Accuracy. | |
| float | WeightedError [get] |
| Weighted error. | |
| float | BalancedError [get] |
| Balanced error. | |
| float | Error [get] |
| Error. | |
| float | WeightedIntersectionOverUnion [get] |
| Weighted Intersection over Union (IoU). | |
| float | BalancedIntersectionOverUnion [get] |
| Balanced Intersection over Union (IoU). | |
| float | BlobDetectionAveragePrecision [get] |
| Average precision for blob detection. | |
| float | BlobDetectionBestFScore [get] |
| Best F1-Score of the segmenter for blob detection. | |
| float | BlobDetectionBestFScoreThreshold [get] |
| Classification threshold that achieves the best F1-Score for blob detection. | |
| float | BlobDetectionRecall [get] |
| Recall for blob detection given the current classification threshold (see EDeepLearningDefectDetectionMetrics.ClassificationThreshold). | |
| float | BlobDetectionPrecision [get] |
| Precision for blob detection given the current classification threshold (see EDeepLearningDefectDetectionMetrics.ClassificationThreshold). | |
| float | BlobDetectionFScore [get] |
| F1-Score for defective blob detection given the current classification threshold (see EDeepLearningDefectDetectionMetrics.ClassificationThreshold). | |
| int | NumLabels [get] |
| Number of labels recognized by the segmenter that produced the results aggregated in the metrics. | |
| Properties inherited from eVision.EasyDeepLearning.EDeepLearningDefectDetectionMetrics | |
| int | NumDefectiveSample [get] |
| Number of defective sample added to the metric. | |
| int | NumGoodSample [get] |
| Number of good sample added to the metric. | |
| float | BestAccuracy [get] |
| Best achievable accuracy. | |
| float | BestBalancedAccuracy [get] |
| Best achievable balanced accuracy. | |
| float | BestAccuracyClassificationThreshold [get] |
| Classification threshold giving the best achievable accuracy (see EDeepLearningDefectDetectionMetrics.BestAccuracy). | |
| float | BestBalancedAccuracyClassificationThreshold [get] |
| Classification threshold giving the best achievable balanced accuracy (see EDeepLearningDefectDetectionMetrics.BestBalancedAccuracy). | |
| float | AreaUnderROCCurve [get] |
| The area under ROC curve (AUC) of the classifier (see EDeepLearningDefectDetectionMetrics.GetROCPoint). It's value is between 0 and 1. | |
| float | AveragePrecision [get] |
| Average precision. | |
| float | BestFScore [get] |
| Best F1-Score. | |
| float | BestFScoreThreshold [get] |
| Classification threshold that yields the best F1-Score. | |
| int | PrecisionRecallCurveIndex [get] |
| Index in the precision/recall curve for the current EDeepLearningDefectDetectionMetrics.ClassificationThreshold. | |
| int | NumPrecisionRecallCurvePoint [get] |
| Number of point in the precision/recall curve. | |
| int | NumberOfClassifiers [get] |
| Number of different possible classifiers. | |
| float | ClassificationThreshold [get, set] |
| Classification threshold. | |
Collection of metrics used to evaluate the state of a ESupervisedSegmenter tool.
A metric is a value summarizing the quality of a collection of supervised segmentation results (see ESupervisedSegmenterResult) with respect to their ground truth. The ESupervisedSegmenterMetrics contains three types of metrics:
The pixel metrics are the error (see ESupervisedSegmenterMetrics.Error), the pixel accuracy (see ESupervisedSegmenterMetrics.PixelAccuracy), the pixel confusion (see ESupervisedSegmenterMetrics.GetPixelConfusion), the pixel per-label accuracy (see ESupervisedSegmenterMetrics.GetPixelLabelAccuracy) and the intersection over union (see ESupervisedSegmenterMetrics.GetIntersectionOverUnion).
The blob based metrics are two confusion matrices (ESupervisedSegmenterMetrics.GetGroundtruthBlobConfusion and ESupervisedSegmenterMetrics.GetPredictedBlobConfusion), and various defect detection metrics (ESupervisedSegmenterMetrics.BlobDetectionRecall, ESupervisedSegmenterMetrics.BlobDetectionPrecision, and ESupervisedSegmenterMetrics.BlobDetectionFScore). Note that the metrics for defective blob detection are different from the metrics for defective image detection because, in the case of blob detection, we have no "good" ground truth results.
See EDeepLearningDefectDetectionMetrics for a description of the defect detection metrics. These metrics are available when EDeepLearningDefectDetectionMetrics.IsDefectDetectionMetricsValid is true, i.e. when both images that are entirely background and images with non-background pixels have been added to the metrics.
Most metrics depends upon the EDeepLearningDefectDetectionMetrics.ClassificationThreshold.
License(s): BasicTypes
| eVision.EasyDeepLearning.ESupervisedSegmenterMetrics.ESupervisedSegmenterMetrics | ( | ) |
Constructs an ESupervisedSegmenterMetrics object.
| eVision.EasyDeepLearning.ESupervisedSegmenterMetrics.ESupervisedSegmenterMetrics | ( | eVision.EasyDeepLearning.ESupervisedSegmenterMetrics | other | ) |
Copy constructor of an ESupervisedSegmenterMetrics object.
| other | Reference to the ESupervisedSegmenterMetrics object that should be copied |
| ulong eVision.EasyDeepLearning.ESupervisedSegmenterMetrics.GetGroundtruthBlobConfusion | ( | int | groundtruthLabelIndex, |
| int | predictedLabelIndex ) |
Number of ground truth blobs of the given ground truth label that best match with blobs of the given predicted label.
See ESupervisedSegmenterMetrics.GetPredictedBlobConfusion for the number of predicted blobs that match to these ground truth blobs.
| groundtruthLabelIndex | Ground truth label index |
| predictedLabelIndex | Predicted label index |
A ground truth blob is matched to the subset of predicted blobs from the same predicted label that has the best intersection over union with the ground truth blob. Otherwise, the ground truth blob is matched to background.
| ulong eVision.EasyDeepLearning.ESupervisedSegmenterMetrics.GetGroundtruthBlobConfusion | ( | string | groundtruthLabel, |
| string | predictedLabel ) |
Number of ground truth blobs of the given ground truth label that best match with blobs of the given predicted label.
See ESupervisedSegmenterMetrics.GetPredictedBlobConfusion for the number of predicted blobs that match to these ground truth blobs.
| groundtruthLabel | Ground truth label |
| predictedLabel | Predicted label |
A ground truth blob is matched to the subset of predicted blobs from the same predicted label that has the best intersection over union with the ground truth blob. Otherwise, the ground truth blob is matched to background.
| float eVision.EasyDeepLearning.ESupervisedSegmenterMetrics.GetIntersectionOverUnion | ( | string | label | ) |
Intersection over union.
The intersection over union if the ratio between the number of correctly classified pixels from the given label to the total number of pixels that belongs to that label or are predicted as being from that label.
Assuming that the given label is the positive class, the intersection over union is expressed as IOU = TP / (TP + FP + FN) where TP is the number of true positive, FP the number of false positive (pixels that belongs to label but are not predicted as label) and FN the number of false negative (pixels predicted as label but that do not belong to label).
| label | Label |
The intersection over union is also called the Jaccard index.
| string eVision.EasyDeepLearning.ESupervisedSegmenterMetrics.GetLabel | ( | int | labelIdx | ) |
Label recognized by the segmenter that produced the results aggregated in the metrics.
| labelIdx | Index of the label between 0 and ESupervisedSegmenterMetrics.NumLabels - 1. |
| float eVision.EasyDeepLearning.ESupervisedSegmenterMetrics.GetLabelError | ( | string | label | ) |
Label error.
| label | Label |
| float eVision.EasyDeepLearning.ESupervisedSegmenterMetrics.GetNormalizedPixelConfusion | ( | string | trueLabel, |
| string | predictedLabel ) |
Pixel-wise normalized confusion between the given true and predicted labels.
The normalized confusion is the ratio of the number of pixels belonging to the 'trueLabel' that are classified as 'predictedLabel' to the total number of pixels belonging to the 'trueLabel'.
| trueLabel | True label |
| predictedLabel | Predicted label |
| ulong eVision.EasyDeepLearning.ESupervisedSegmenterMetrics.GetPixelConfusion | ( | string | trueLabel, |
| string | predictedLabel ) |
Pixel-wise confusion between the given true and predicted labels.
The confusion is the number of pixels belonging to the 'trueLabel' that are classified as 'predictedLabel'.
| trueLabel | True label |
| predictedLabel | Predicted label |
| float eVision.EasyDeepLearning.ESupervisedSegmenterMetrics.GetPixelLabelAccuracy | ( | string | label | ) |
Pixel label accuracy.
The label accuracy is the ratio of the number of correctly classified pixels of the given class to the total number of ground truth pixels from that class. If there are no ground truth pixels from the requested label, the method returns '-1'.
| label | Label |
| ulong eVision.EasyDeepLearning.ESupervisedSegmenterMetrics.GetPredictedBlobConfusion | ( | int | groundtruthLabelIndex, |
| int | predictedLabelIndex ) |
Number of predicted blobs of the given predicted label that match to blobs of the given ground truth label.
See ESupervisedSegmenterMetrics.GetGroundtruthBlobConfusion for the number of ground truth blobs that match to these predicted blobs.
| groundtruthLabelIndex | Ground truth label index |
| predictedLabelIndex | Predicted label index |
A predicted blob may be counted several times in the confusion matrix for predicted blobs:
| ulong eVision.EasyDeepLearning.ESupervisedSegmenterMetrics.GetPredictedBlobConfusion | ( | string | groundtruthLabel, |
| string | predictedLabel ) |
Number of predicted blobs of the given predicted label that match to blobs of the given ground truth label.
See ESupervisedSegmenterMetrics.GetGroundtruthBlobConfusion for the number of ground truth blobs that match to these predicted blobs.
| groundtruthLabel | Ground truth label |
| predictedLabel | Predicted label |
A predicted blob may be counted several times in the confusion matrix for predicted blobs:
| bool eVision.EasyDeepLearning.ESupervisedSegmenterMetrics.IsValid | ( | ) |
Indicates whether the object contains at least one result.
|
virtual |
Loads an supervised segmentation metric. The given ESerializer must have been created for reading.
| serializer | The serializer. |
Reimplemented from eVision.EasyDeepLearning.EDeepLearningDefectDetectionMetrics.
|
virtual |
Loads an supervised segmentation metric. The given ESerializer must have been created for reading.
| path | The file path. |
Reimplemented from eVision.EasyDeepLearning.EDeepLearningDefectDetectionMetrics.
|
virtual |
Saves an supervised segmentation metric. The given ESerializer must have been created for writing.
| serializer | The serializer. |
Reimplemented from eVision.EasyDeepLearning.EDeepLearningDefectDetectionMetrics.
|
virtual |
Saves an supervised segmentation metric. The given ESerializer must have been created for writing.
| path | The file path. |
Reimplemented from eVision.EasyDeepLearning.EDeepLearningDefectDetectionMetrics.
|
get |
Balanced error.
The balanced error is the weighted error (ESupervisedSegmenterMetrics.WeightedError) where each label is given an equal weight.
The error is also called the cross-entropy loss.
|
get |
Balanced Intersection over Union (IoU).
The balanced intersection over union is the weighted intersection over union (ESupervisedSegmenterMetrics.WeightedIntersectionOverUnion) where each label is given equal weight.
|
get |
Balanced accuracy.
The balanced accuracy is the weighted accuracy (ESupervisedSegmenterMetrics.WeightedPixelAccuracy) where each label is given an equal weight.
|
get |
Average precision for blob detection.
Blob detection is the ability of the segmenter to correctly detect foreground ground truth blobs, regardless of their specific label. The average precision for blob detection is the average of the precision (see ESupervisedSegmenterMetrics.BlobDetectionPrecision) over all the possible classification threshold values. As such, the average precision does not depend on a specific classification threshold.
|
get |
Best F1-Score of the segmenter for blob detection.
See ESupervisedSegmenterMetrics.BlobDetectionBestFScoreThreshold for the corresponding threshold.
See EDeepLearningDefectDetectionMetrics.GetFScore for a definition of the F1-Score. Blob detection is the ability of the segmenter to correctly detect foreground ground truth blobs, regardless of their specific label.
|
get |
Classification threshold that achieves the best F1-Score for blob detection.
See ESupervisedSegmenterMetrics.BlobDetectionBestFScore for the corresponding F1-Score.
See EDeepLearningDefectDetectionMetrics.GetFScore for a definition of the F1-Score. Blob detection is the ability of the segmenter to correctly detect foreground ground truth blobs, regardless of their specific label.
|
get |
F1-Score for defective blob detection given the current classification threshold (see EDeepLearningDefectDetectionMetrics.ClassificationThreshold).
See ESupervisedSegmenterMetrics.BlobDetectionBestFScore for the corresponding F1-Score.
See EDeepLearningDefectDetectionMetrics.GetFScore for a definition of the F1-Score. Blob detection is the ability of the segmenter to correctly detect foreground ground truth blobs, regardless of their specific label.
|
get |
Precision for blob detection given the current classification threshold (see EDeepLearningDefectDetectionMetrics.ClassificationThreshold).
The precision is the proportion of detected defective blobs that match ground truth defective blobs.
Blob detection is the ability of the segmenter to correctly detect foreground ground truth blobs, regardless of their specific label.
|
get |
Recall for blob detection given the current classification threshold (see EDeepLearningDefectDetectionMetrics.ClassificationThreshold).
The recall is the proportion of ground truth defective blobs that are matched to predicted defective blobs.
Blob detection is the ability of the segmenter to correctly detect foreground ground truth blobs, regardless of their specific label.
|
get |
Error.
The error is also called the cross-entropy loss.
|
get |
Number of labels recognized by the segmenter that produced the results aggregated in the metrics.
|
get |
Accuracy.
The accuracy is the ratio of the number of correctly classified pixels to the total number of pixels.
The accuracy will be skewed towards the most represented labels in the dataset. For example, if your dataset has 1% of defective pixels, the accuracy will mostly reflect the results on the 99% of good pixels and will say nothing about the capability of the model to detect the defect labels.
|
get |
Weighted error.
The weighted error is the weighted average of each label error (ESupervisedSegmenterMetrics.GetLabelError) with respect to the dataset label weights.
The error is also called the cross-entropy loss.
|
get |
Weighted Intersection over Union (IoU).
The weighted intersection over union is the weighted averaged of each label intersection over union (see ESupervisedSegmenterMetrics.GetIntersectionOverUnion) with respect to the dataset label weights.
|
get |
Weighted accuracy.
The weighted accuracy is the weighted average of each label accuracy (ESupervisedSegmenterMetrics.GetPixelLabelAccuracy) with respect to the dataset label weights.
 1.17.0