 |
eVision Python API
|
|
eVision Python API
|
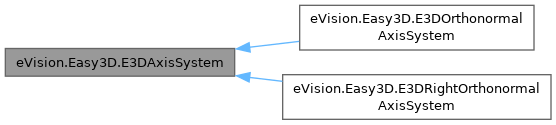
Represent a 3D base axis system. More...
Public Member Functions | |
| None | __init__ (self) |
| Constructs an eVision.Easy3D.E3DAxisSystem. | |
| None | __init__ (self, eVision.Easy3D.E3DPoint Origin, eVision.Easy3D.E3DPoint axisX, eVision.Easy3D.E3DPoint axisY, eVision.Easy3D.E3DPoint axisZ) |
| Constructs an eVision.Easy3D.E3DAxisSystem. | |
| None | __init__ (self, eVision.Easy3D.E3DAxisSystem other) |
| Constructs an eVision.Easy3D.E3DAxisSystem. | |
| bool | IsRightHanded (self) |
| return true if this base axis system is Right Handed | |
| bool | IsOrthogonal (self) |
| return true if this base axis system is Orthogonal | |
| bool | IsNormal (self) |
| return true if this base axis system is Normed | |
| None | Load (self, str path) |
| Load the eVision.Easy3D.E3DAxisSystem configuration. | |
| None | Load (self, eVision.ESerializer|None serializer) |
| Load the eVision.Easy3D.E3DAxisSystem configuration. | |
| None | Save (self, str path) |
| Save the eVision.Easy3D.E3DAxisSystem configuration. | |
| None | Save (self, eVision.ESerializer|None serializer) |
| Save the eVision.Easy3D.E3DAxisSystem configuration. | |
| eVision.Easy3D.E3DPoint | Origin (self) |
| Gets the origin. | |
| eVision.Easy3D.E3DPoint | AxisX (self) |
| Gets the X axis. | |
| eVision.Easy3D.E3DPoint | AxisY (self) |
| Gets the Y axis. | |
| eVision.Easy3D.E3DPoint | AxisZ (self) |
| Gets the Z axis. | |
| float | NormX (self) |
| Gets the norm of the X axis. | |
| float | NormY (self) |
| Gets the norm of the Y axis. | |
| float | NormZ (self) |
| Gets the norm of the Z axis. | |
Static Public Member Functions | |
| bool | CheckIsOrthogonal (eVision.Easy3D.E3DPoint axisX, eVision.Easy3D.E3DPoint axisY, eVision.Easy3D.E3DPoint axisZ) |
| check if the given axis system is Orthogonal | |
| bool | CheckIsNormal (eVision.Easy3D.E3DPoint axisX, eVision.Easy3D.E3DPoint axisY, eVision.Easy3D.E3DPoint axisZ) |
| check if the given axis system is Normed | |
| bool | CheckIsRightHanded (eVision.Easy3D.E3DPoint axisX, eVision.Easy3D.E3DPoint axisY, eVision.Easy3D.E3DPoint axisZ) |
| check if the given axis system is Right | |
| None eVision.Easy3D.E3DAxisSystem.__init__ | ( | self | ) |
Constructs an eVision.Easy3D.E3DAxisSystem.
| None eVision.Easy3D.E3DAxisSystem.__init__ | ( | self, | |
| eVision.Easy3D.E3DPoint | Origin, | ||
| eVision.Easy3D.E3DPoint | axisX, | ||
| eVision.Easy3D.E3DPoint | axisY, | ||
| eVision.Easy3D.E3DPoint | axisZ ) |
Constructs an eVision.Easy3D.E3DAxisSystem.
| Origin | The origin of the axis system |
| axisX | The X axis |
| axisY | The Y axis |
| axisZ | The Z axis |
| None eVision.Easy3D.E3DAxisSystem.__init__ | ( | self, | |
| eVision.Easy3D.E3DAxisSystem | other ) |
Constructs an eVision.Easy3D.E3DAxisSystem.
| other | Reference to another eVision.Easy3D.E3DAxisSystem used for the initialization. |
| eVision.Easy3D.E3DPoint eVision.Easy3D.E3DAxisSystem.AxisX | ( | self | ) |
Gets the X axis.
| eVision.Easy3D.E3DPoint eVision.Easy3D.E3DAxisSystem.AxisY | ( | self | ) |
Gets the Y axis.
| eVision.Easy3D.E3DPoint eVision.Easy3D.E3DAxisSystem.AxisZ | ( | self | ) |
Gets the Z axis.
|
static |
check if the given axis system is Normed
| axisX | eVision.Easy3D.E3DPoint representing the X-axis of the system. |
| axisY | eVision.Easy3D.E3DPoint representing the Y-axis of the system. |
| axisZ | eVision.Easy3D.E3DPoint representing the Z-axis of the system. |
|
static |
check if the given axis system is Orthogonal
| axisX | eVision.Easy3D.E3DPoint representing the X-axis of the system. |
| axisY | eVision.Easy3D.E3DPoint representing the Y-axis of the system. |
| axisZ | eVision.Easy3D.E3DPoint representing the Z-axis of the system. |
|
static |
check if the given axis system is Right
| axisX | eVision.Easy3D.E3DPoint representing the X-axis of the system. |
| axisY | eVision.Easy3D.E3DPoint representing the Y-axis of the system. |
| axisZ | eVision.Easy3D.E3DPoint representing the Z-axis of the system. |
| bool eVision.Easy3D.E3DAxisSystem.IsNormal | ( | self | ) |
return true if this base axis system is Normed
| bool eVision.Easy3D.E3DAxisSystem.IsOrthogonal | ( | self | ) |
return true if this base axis system is Orthogonal
| bool eVision.Easy3D.E3DAxisSystem.IsRightHanded | ( | self | ) |
return true if this base axis system is Right Handed
| None eVision.Easy3D.E3DAxisSystem.Load | ( | self, | |
| eVision.ESerializer | None | serializer ) |
Load the eVision.Easy3D.E3DAxisSystem configuration.
The given eVision.ESerializer must have been created for reading.
| serializer | The serializer. |
| None eVision.Easy3D.E3DAxisSystem.Load | ( | self, | |
| str | path ) |
Load the eVision.Easy3D.E3DAxisSystem configuration.
The given eVision.ESerializer must have been created for reading.
| path | The file path. |
| float eVision.Easy3D.E3DAxisSystem.NormX | ( | self | ) |
Gets the norm of the X axis.
| float eVision.Easy3D.E3DAxisSystem.NormY | ( | self | ) |
Gets the norm of the Y axis.
| float eVision.Easy3D.E3DAxisSystem.NormZ | ( | self | ) |
Gets the norm of the Z axis.
| eVision.Easy3D.E3DPoint eVision.Easy3D.E3DAxisSystem.Origin | ( | self | ) |
Gets the origin.
| None eVision.Easy3D.E3DAxisSystem.Save | ( | self, | |
| eVision.ESerializer | None | serializer ) |
Save the eVision.Easy3D.E3DAxisSystem configuration.
The given eVision.ESerializer must have been created for writing.
| serializer | The serializer. |
| None eVision.Easy3D.E3DAxisSystem.Save | ( | self, | |
| str | path ) |
Save the eVision.Easy3D.E3DAxisSystem configuration.
The given eVision.ESerializer must have been created for writing.
| path | The file path. |
 1.17.0