 |
eVision Python API
|
|
eVision Python API
|
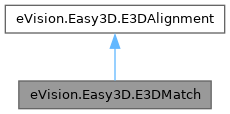
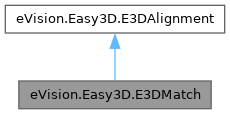
Represents a 3D match returned by eVision.Easy3D.E3DMatcher. More...
Public Member Functions | |
| None | __init__ (self) |
| Constructs an eVision.Easy3D.E3DMatch. | |
| None | __init__ (self, eVision.Easy3D.E3DMatch other) |
| Constructs an eVision.Easy3D.E3DMatch. | |
| None | __init__ (self, eVision.Easy3D.E3DAlignment other) |
| Constructs an eVision.Easy3D.E3DMatch. | |
| list[eVision._eVision.Easy3D.E3DAnomaly] | Anomalies (self) |
| Gets the list of eVision.Easy3D.E3DAnomaly of the eVision.Easy3D.E3DMatch. | |
| Public Member Functions inherited from eVision.Easy3D.E3DAlignment | |
| None | __init__ (self) |
| Constructs an eVision.Easy3D.E3DAlignment. | |
| None | __init__ (self, eVision.Easy3D.E3DAlignment other) |
| Constructs an eVision.Easy3D.E3DAlignment. | |
| eVision.Easy3D.E3DTransformMatrix | Pose (self) |
| Gets the pose of the eVision.Easy3D.E3DAlignment. | |
| float | Error (self) |
| Gets the eVision.Easy3D.E3DAlignment error. | |
| int | RefPoseMatchedIndex (self) |
| Gets the reference pose index to which the scan was matched. | |
| None eVision.Easy3D.E3DMatch.__init__ | ( | self | ) |
Constructs an eVision.Easy3D.E3DMatch.
| None eVision.Easy3D.E3DMatch.__init__ | ( | self, | |
| eVision.Easy3D.E3DMatch | other ) |
Constructs an eVision.Easy3D.E3DMatch.
| other | Another eVision.Easy3D.E3DMatch object to be copied in the new eVision.Easy3D.E3DMatch object. |
| None eVision.Easy3D.E3DMatch.__init__ | ( | self, | |
| eVision.Easy3D.E3DAlignment | other ) |
Constructs an eVision.Easy3D.E3DMatch.
| other | Another eVision.Easy3D.E3DMatch object to be copied in the new eVision.Easy3D.E3DMatch object. |
| list[eVision._eVision.Easy3D.E3DAnomaly] eVision.Easy3D.E3DMatch.Anomalies | ( | self | ) |
Gets the list of eVision.Easy3D.E3DAnomaly of the eVision.Easy3D.E3DMatch.
The anomalies represent zones where there are important discrepancies between the sample and the reference.
 1.17.0