 |
eVision .NET API
|
|
eVision .NET API
|
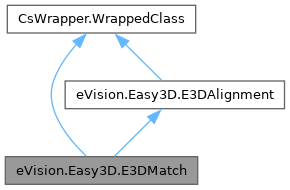
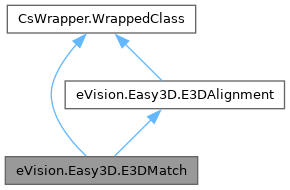
Represents a 3D match returned by E3DMatcher. More...
Public Member Functions | |
| E3DMatch () | |
| Constructs an E3DMatch. | |
| E3DMatch (eVision.Easy3D.E3DMatch other) | |
| Constructs an E3DMatch. | |
| E3DMatch (eVision.Easy3D.E3DAlignment other) | |
| Constructs an E3DMatch. | |
| Public Member Functions inherited from eVision.Easy3D.E3DAlignment | |
| E3DAlignment () | |
| Constructs an E3DAlignment. | |
| E3DAlignment (eVision.Easy3D.E3DAlignment other) | |
| Constructs an E3DAlignment. | |
Properties | |
| eVision.Easy3D.E3DAnomaly[] | Anomalies [get] |
| Gets the list of E3DAnomaly of the E3DMatch. The anomalies represent zones where there are important discrepancies between the sample and the reference. | |
| Properties inherited from eVision.Easy3D.E3DAlignment | |
| eVision.Easy3D.E3DTransformMatrix | Pose [get] |
| Gets the pose of the E3DAlignment. The pose is an E3DTransformMatrix to apply to the scan to align it on the reference. | |
| float | Error [get] |
| Gets the E3DAlignment error. The lower the error, the better the alignment. The error represents the average euclidean distance between the points of the reference and the scan without taking outliers into account. | |
| int | RefPoseMatchedIndex [get] |
| Gets the reference pose index to which the scan was matched. These reference poses can be obtained by using E3DAligner.RetrieveReferencePosesProjections. | |
Represents a 3D match returned by E3DMatcher.
License(s): Easy3DMatch
| eVision.Easy3D.E3DMatch.E3DMatch | ( | ) |
Constructs an E3DMatch.
| eVision.Easy3D.E3DMatch.E3DMatch | ( | eVision.Easy3D.E3DMatch | other | ) |
| eVision.Easy3D.E3DMatch.E3DMatch | ( | eVision.Easy3D.E3DAlignment | other | ) |
|
get |
Gets the list of E3DAnomaly of the E3DMatch. The anomalies represent zones where there are important discrepancies between the sample and the reference.
 1.17.0