 |
eVision .NET API
|
|
eVision .NET API
|
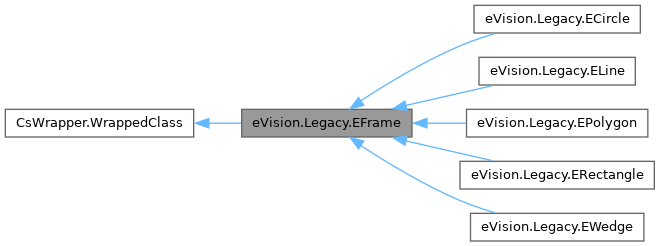
Represents a geometrical frame of reference as well as the parameters needed to transform from/to local and global coordinates. It contains a point and an angle and serves as a base class for geometrical elements. More...
Public Member Functions | |
| EFrame () | |
| Constructs a EFrame object. | |
| EFrame (float centerX, float centerY, float angle, float scale) | |
| Constructs a EFrame object. | |
| EFrame (float centerX, float centerY, float angle) | |
| Constructs a EFrame object. | |
| EFrame (float centerX, float centerY) | |
| Constructs a EFrame object. | |
| EFrame (eVision.EPoint center, float angle, float scale) | |
| Constructs a EFrame object. | |
| EFrame (eVision.Legacy.EFrame frame) | |
| Constructs a EFrame object. | |
| void | CopyTo (eVision.Legacy.EFrame other) |
| Copies all the data from the current EFrame object into another EFrame object, and returns it. | |
| eVision.EPoint | LocalToGlobal (eVision.EPoint local) |
| Transforms a geometrical element from local to global coordinates (local to world). | |
| eVision.Legacy.EFrame | LocalToGlobal (eVision.Legacy.EFrame local) |
| Transforms a geometrical element from local to global coordinates (local to world). | |
| eVision.Legacy.ELine | LocalToGlobal (eVision.Legacy.ELine local) |
| Transforms a geometrical element from local to global coordinates (local to world). | |
| eVision.Legacy.ECircle | LocalToGlobal (eVision.Legacy.ECircle local) |
| Transforms a geometrical element from local to global coordinates (local to world). | |
| eVision.EPoint | GlobalToLocal (eVision.EPoint global) |
| Transforms a geometrical element from global to local coordinates (world to local). | |
| eVision.Legacy.EFrame | GlobalToLocal (eVision.Legacy.EFrame global) |
| Transforms a geometrical element from global to local coordinates (world to local). | |
| void | Load (string path) |
| Load the EFrame configuration. The given ESerializer must have been created for reading. | |
| void | Load (eVision.ESerializer serializer) |
| Load the EFrame configuration. The given ESerializer must have been created for reading. | |
| void | Save (string path) |
| Save the EFrame configuration. The given ESerializer must have been created for writing. | |
| void | Save (eVision.ESerializer serializer) |
| Save the EFrame configuration. The given ESerializer must have been created for writing. | |
| void | SetCenterXY (float centerX, float centerY) |
| Sets the center coordinates of a EFrame object. | |
| eVision.EPoint | MidPoint (eVision.EPoint Point) |
| Returns the middle coordinate between this EFrame object's center and another EFrame object's center. | |
| eVision.EPoint | Rotate (float angle) |
| Returns another EPoint object containing the coordinates of the rotated center point. | |
| float | Square () |
| Compute the sum of the squared coordinates of the center of a EFrame. | |
| float | Modulus () |
| Compute the euclidean modulus of the center of a EFrame. | |
| float | Argument () |
| Compute the polar argument of the center of EFrame object. | |
| float | Dot (eVision.EPoint Point) |
| Compute the dot product of the centers of two EFrame objects. | |
| float | Cross (eVision.EPoint Point) |
| Compute the cross product of the centers of two EFrame objects. | |
| float | Area (eVision.EPoint Point) |
| Compute the oriented area of the parallelogram built on the centers of two EFrame. | |
| eVision.EPoint | Project (eVision.Legacy.ELine shape) |
| Compute the orthogonal projection of the center of a EFrame on another shape. | |
| eVision.EPoint | Project (eVision.Legacy.ECircle shape) |
| Compute the orthogonal projection of the center of a EFrame on another shape. | |
| float | SquaredDistance (eVision.EPoint Point) |
| Compute the squared distance between the centers of two EFrame. | |
| eVision.EPoint | Move (float angle, float distance) |
| Return the position by moving the center along angle by distance. | |
| virtual float | Distance (eVision.EPoint point) |
| Returns the distance between the addressed point and the center of EFrame object. | |
| virtual float | Distance (eVision.Legacy.ELine line, bool segmentOnly) |
| Returns the distance between the addressed point and the center of EFrame object. | |
| virtual float | Distance (eVision.Legacy.ELine line) |
| Returns the distance between the addressed point and the center of EFrame object. | |
| virtual float | Distance (eVision.Legacy.ECircle circle, bool arcOnly) |
| Returns the distance between the addressed point and the center of EFrame object. | |
| virtual float | Distance (eVision.Legacy.ECircle circle) |
| Returns the distance between the addressed point and the center of EFrame object. | |
Static Public Member Functions | |
| static eVision.EPoint | operator+ (eVision.Legacy.EFrame extraArgument, eVision.EPoint point) |
| Returns the addition of the point to the center of the EFrame. | |
| static eVision.EPoint | operator- (eVision.Legacy.EFrame extraArgument, eVision.EPoint point) |
| Returns the substraction of the center of the EFrame with the given point. | |
| static eVision.EPoint | operator* (eVision.Legacy.EFrame extraArgument, float scalar) |
| Returns the multiplication of the center of the EFrame with the given multiplier. | |
| static eVision.EPoint | operator/ (eVision.Legacy.EFrame extraArgument, float scalar) |
| Returns the division of the center of the EFrame with the given divisor. | |
Properties | |
| float | Angle [get, set] |
| Orientation of the frame. | |
| float | Scale [get, set] |
| Horizontal sensor resolution, in pixels per unit. | |
| float | CenterX [get] |
| Abscissa of the origin point of the frame. | |
| float | CenterY [get] |
| Ordinate of the origin point of the frame. | |
| virtual eVision.EPoint | Center [get, set] |
| Center. | |
| float | X [get, set] |
| Abscissa (X coordinate) of the EFrame object. | |
| float | Y [get, set] |
| Ordinate (Y coordinate) of the EFrame object. | |
Represents a geometrical frame of reference as well as the parameters needed to transform from/to local and global coordinates. It contains a point and an angle and serves as a base class for geometrical elements.
License(s): BasicTypes
| eVision.Legacy.EFrame.EFrame | ( | ) |
Constructs a EFrame object.
| eVision.Legacy.EFrame.EFrame | ( | float | centerX, |
| float | centerY, | ||
| float | angle, | ||
| float | scale ) |
Constructs a EFrame object.
| centerX | Abscissa of the center point of the frame. |
| centerY | Ordinate of the center point of the frame. |
| angle | Orientation of the frame. |
| scale | Horizontal sensor resolution. |
| eVision.Legacy.EFrame.EFrame | ( | float | centerX, |
| float | centerY, | ||
| float | angle ) |
Constructs a EFrame object.
| centerX | Abscissa of the center point of the frame. |
| centerY | Ordinate of the center point of the frame. |
| angle | Orientation of the frame. |
| eVision.Legacy.EFrame.EFrame | ( | float | centerX, |
| float | centerY ) |
Constructs a EFrame object.
| centerX | Abscissa of the center point of the frame. |
| centerY | Ordinate of the center point of the frame. |
| eVision.Legacy.EFrame.EFrame | ( | eVision.EPoint | center, |
| float | angle, | ||
| float | scale ) |
Constructs a EFrame object.
| center | Coordinates of the center point of the frame. |
| angle | Orientation of the frame. |
| scale | Horizontal sensor resolution. |
| eVision.Legacy.EFrame.EFrame | ( | eVision.Legacy.EFrame | frame | ) |
| float eVision.Legacy.EFrame.Area | ( | eVision.EPoint | Point | ) |
Compute the oriented area of the parallelogram built on the centers of two EFrame.
| Point | Second edge of the parallelogram. |
Compute the oriented area of the parallelogram built on the center of two EFrame. The area is counted as positive if the oriented vector pair ('first edge', 'second edge') is in the same sense that the axis frame. This oriented area can also be viewed as the z-coordinate of a vector product of two 3D vectors obtained in supplementing each edges with a third z-coordinate (set to zero).
| float eVision.Legacy.EFrame.Argument | ( | ) |
| void eVision.Legacy.EFrame.CopyTo | ( | eVision.Legacy.EFrame | other | ) |
Copies all the data from the current EFrame object into another EFrame object, and returns it.
| other | Pointer to the EFrame object in which the current EFrame object data have to be copied. |
In the overload taking a pointer, in case of a NULL pointer, a new EFrame object will be created and returned.
| float eVision.Legacy.EFrame.Cross | ( | eVision.EPoint | Point | ) |
Compute the cross product of the centers of two EFrame objects.
| Point | Second factor of the cross product. |
|
virtual |
Returns the distance between the addressed point and the center of EFrame object.
| point | EPoint object with which to calculate the distance. |
Many EasyGauge members provide measurement result as a EPoint object (see EPointGauge.Center, EPointGauge.GetMeasuredPoint,...). The EFrame class has its own members to retrieve all the information pertaining to a point. Among them, the Distance method returns the distance between a point pair or between a point and a line segment, a circle arc or a rectangle.
|
virtual |
Returns the distance between the addressed point and the center of EFrame object.
| circle | ECircle object with which to calculate the distance. |
Many EasyGauge members provide measurement result as a EPoint object (see EPointGauge.Center, EPointGauge.GetMeasuredPoint,...). The EFrame class has its own members to retrieve all the information pertaining to a point. Among them, the Distance method returns the distance between a point pair or between a point and a line segment, a circle arc or a rectangle.
Reimplemented in eVision.Legacy.ECircle.
|
virtual |
Returns the distance between the addressed point and the center of EFrame object.
| circle | ECircle object with which to calculate the distance. |
| arcOnly | By default (false), the circle is not restricted to an arc. |
Many EasyGauge members provide measurement result as a EPoint object (see EPointGauge.Center, EPointGauge.GetMeasuredPoint,...). The EFrame class has its own members to retrieve all the information pertaining to a point. Among them, the Distance method returns the distance between a point pair or between a point and a line segment, a circle arc or a rectangle.
|
virtual |
Returns the distance between the addressed point and the center of EFrame object.
| line | ELine object with which to calculate the distance. |
| segmentOnly | By default (false), the line is not restricted to a segment. |
Many EasyGauge members provide measurement result as a EPoint object (see EPointGauge.Center, EPointGauge.GetMeasuredPoint,...). The EFrame class has its own members to retrieve all the information pertaining to a point. Among them, the Distance method returns the distance between a point pair or between a point and a line segment, a circle arc or a rectangle.
| float eVision.Legacy.EFrame.Dot | ( | eVision.EPoint | Point | ) |
Compute the dot product of the centers of two EFrame objects.
| Point | Second factor of the dot product. |
| eVision.EPoint eVision.Legacy.EFrame.GlobalToLocal | ( | eVision.EPoint | global | ) |
Transforms a geometrical element from global to local coordinates (world to local).
| global | The element, expressed in global coordinates. |
| eVision.Legacy.EFrame eVision.Legacy.EFrame.GlobalToLocal | ( | eVision.Legacy.EFrame | global | ) |
Transforms a geometrical element from global to local coordinates (world to local).
| global | The element, expressed in global coordinates. |
| void eVision.Legacy.EFrame.Load | ( | eVision.ESerializer | serializer | ) |
Load the EFrame configuration. The given ESerializer must have been created for reading.
| serializer | The serializer. |
| void eVision.Legacy.EFrame.Load | ( | string | path | ) |
Load the EFrame configuration. The given ESerializer must have been created for reading.
| path | The file path. |
| eVision.EPoint eVision.Legacy.EFrame.LocalToGlobal | ( | eVision.EPoint | local | ) |
Transforms a geometrical element from local to global coordinates (local to world).
| local | The element, expressed in local coordinates. |
| eVision.Legacy.ECircle eVision.Legacy.EFrame.LocalToGlobal | ( | eVision.Legacy.ECircle | local | ) |
Transforms a geometrical element from local to global coordinates (local to world).
| local | The element, expressed in local coordinates. |
| eVision.Legacy.EFrame eVision.Legacy.EFrame.LocalToGlobal | ( | eVision.Legacy.EFrame | local | ) |
Transforms a geometrical element from local to global coordinates (local to world).
| local | The element, expressed in local coordinates. |
| eVision.Legacy.ELine eVision.Legacy.EFrame.LocalToGlobal | ( | eVision.Legacy.ELine | local | ) |
Transforms a geometrical element from local to global coordinates (local to world).
| local | The element, expressed in local coordinates. |
| eVision.EPoint eVision.Legacy.EFrame.MidPoint | ( | eVision.EPoint | Point | ) |
| float eVision.Legacy.EFrame.Modulus | ( | ) |
| eVision.EPoint eVision.Legacy.EFrame.Move | ( | float | angle, |
| float | distance ) |
Return the position by moving the center along angle by distance.
| angle | The direction of the displacement, in radians. |
| distance | The distance of the displacement. |
|
static |
Returns the multiplication of the center of the EFrame with the given multiplier.
| scalar | The multiplier. |
Use EFrame.Center * scalar instead.
Deprecated in version 25.10. Scheduled to be removed in version 27.6.
|
static |
Returns the addition of the point to the center of the EFrame.
| point | A point. |
Use EFrame.Center + point instead.
Deprecated in version 25.10. Scheduled to be removed in version 27.6.
|
static |
Returns the substraction of the center of the EFrame with the given point.
| point | A point. |
Use EFrame.Center - point instead.
Deprecated in version 25.10. Scheduled to be removed in version 27.6.
|
static |
Returns the division of the center of the EFrame with the given divisor.
| scalar | The divisor. |
Use EFrame.Center / scalar instead.
Deprecated in version 25.10. Scheduled to be removed in version 27.6.
| eVision.EPoint eVision.Legacy.EFrame.Project | ( | eVision.Legacy.ECircle | shape | ) |
| eVision.EPoint eVision.Legacy.EFrame.Project | ( | eVision.Legacy.ELine | shape | ) |
| eVision.EPoint eVision.Legacy.EFrame.Rotate | ( | float | angle | ) |
Returns another EPoint object containing the coordinates of the rotated center point.
| angle | Rotation angle (in radians) |
Rotates a EFrame around the origin (0, 0) by an angle of angle radians. By definition, the smallest (in absolute value) rotation of the oriented X-Axis toward the oriented Y-Axis is chosen as the positive sense of rotation. In a direct frame, this is also the trigonometric sense (counter clockwise).
| void eVision.Legacy.EFrame.Save | ( | eVision.ESerializer | serializer | ) |
Save the EFrame configuration. The given ESerializer must have been created for writing.
| serializer | The serializer. |
| void eVision.Legacy.EFrame.Save | ( | string | path | ) |
Save the EFrame configuration. The given ESerializer must have been created for writing.
| path | The file path. |
| void eVision.Legacy.EFrame.SetCenterXY | ( | float | centerX, |
| float | centerY ) |
Sets the center coordinates of a EFrame object.
| centerX | Center coordinates of the origin. |
| centerY | Center coordinates of the origin. |
| float eVision.Legacy.EFrame.Square | ( | ) |
| float eVision.Legacy.EFrame.SquaredDistance | ( | eVision.EPoint | Point | ) |
|
getset |
Orientation of the frame.
|
getset |
Center.
|
get |
Abscissa of the origin point of the frame.
|
get |
Ordinate of the origin point of the frame.
|
getset |
Horizontal sensor resolution, in pixels per unit.
|
getset |
Abscissa (X coordinate) of the EFrame object.
|
getset |
Ordinate (Y coordinate) of the EFrame object.
 1.17.0