Easy3D - Tools for 3D Object Processing
Easy3D is a set of tools for solving computer vision problems using 3D acquisition and processing. The user can also create, load, save and manipulate 3D depth maps, ZMaps, point clouds and meshes in full-fledged 3D environments.
All Easy3D tools are located within the Easy3D .NET Python namespace.
3D Representation
eVision uses a right-handed cartesian 3D coordinate system. In this system, each 3D point is represented by its 3 coordinates X, Y and Z.
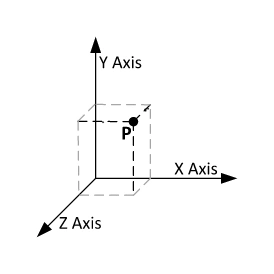
Cartesian coordinate system.
eVision provides different containers to store 3D objects.
E3DPoint
The object E3DPoint .NET Python represents points in a 3D space. An E3DPoint .NET Python is the basic container for data processing in a 3D space.
E3DLine
The object E3DLine .NET Python represents lines in a 3D space.
E3DPlane
The object E3DPlane .NET Python represents planes in a 3D space.
An
E3DPlane.NET Python is defined by its normal vector and the signed distance to the origin of the axes.Use the function
E3DPlane::DistanceTo.NET Python to compute the distance to any point.Use the function
E3DPlane::ProjectPoint.NET Python to project points onto planes.Use the function
E3DPlane::Transform.NET Python with transformation matrices to rotate and translate planes.
E3DSphere
The object E3DSphere .NET Python represents spheres in a 3D space.
An
E3DSphere.NET Python is defined by its center point and its radius.Use the function
E3DSphere::DistanceTo.NET Python to compute the distance to any point.Use the function
E3DSphere::Transform.NET Python with transformation matrices to rotate and translate spheres.
E3DBox
An E3DBox .NET Python is a rectangular parallelepiped in a 3D space. It can have any orientation and be centered on any point in the 3D space.
E3DObject
In eVision, an E3DObject .NET Python is a geometric representation of a set of 3D points.
Use the
E3DObject.NET Python to get the characteristics such as the extend along the 3 axes, the area, the total volume and the average position of the set of points.Use the function
E3DObject::GetBasePlane.NET Python to get the fitted plane of the set of points.Use the function
E3DObject::GetBoundingBox.NET Python to get the bounding box, represented by aE3DBox.NET Python enclosing the set of points.